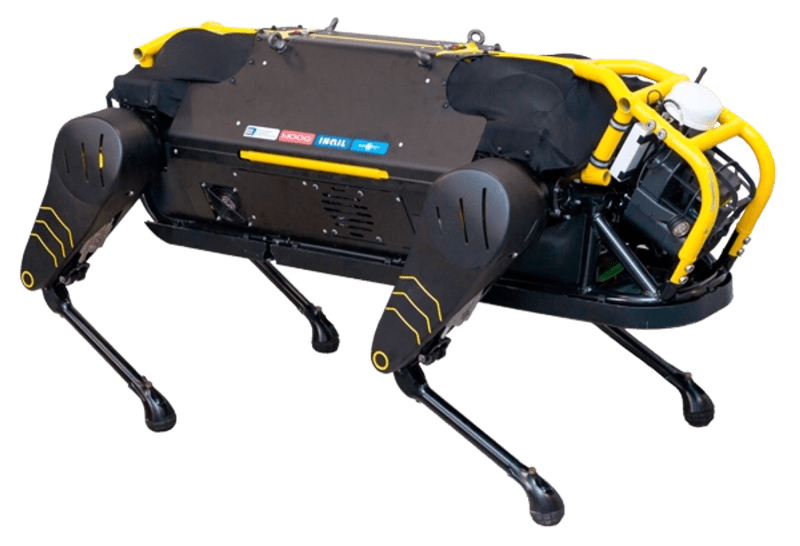
HyQReal
by Italian Institute of Technology (IIT)
ItalyReleased: 2019
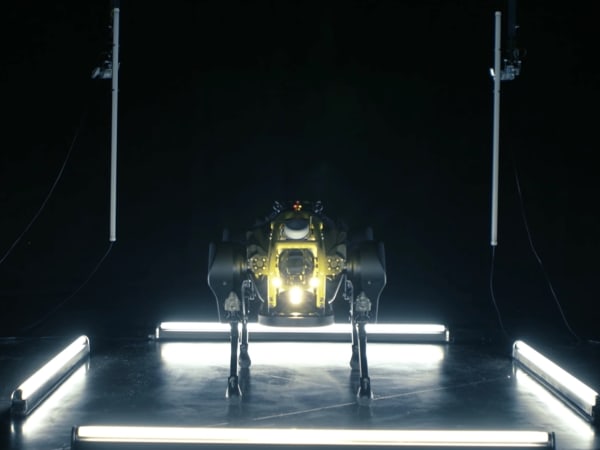
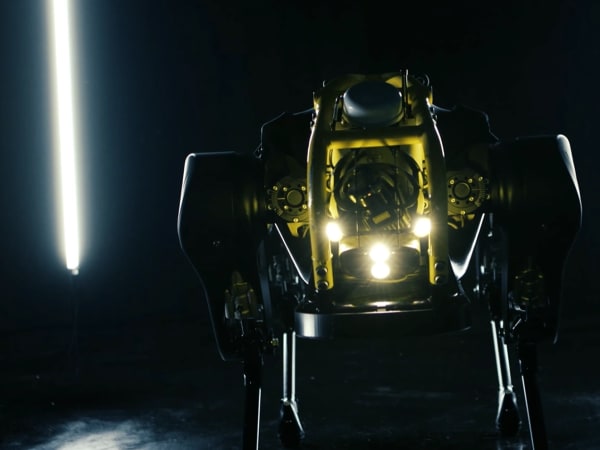
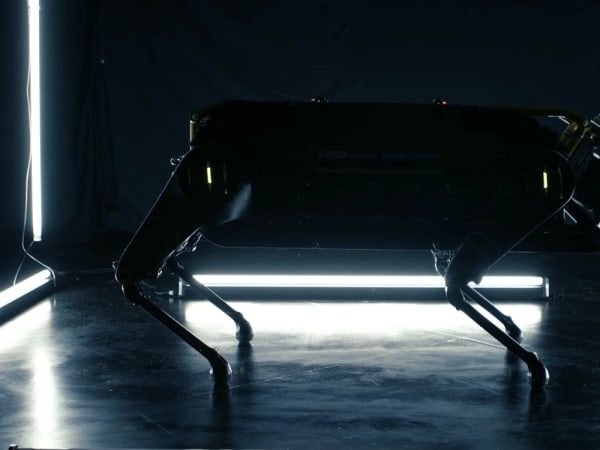
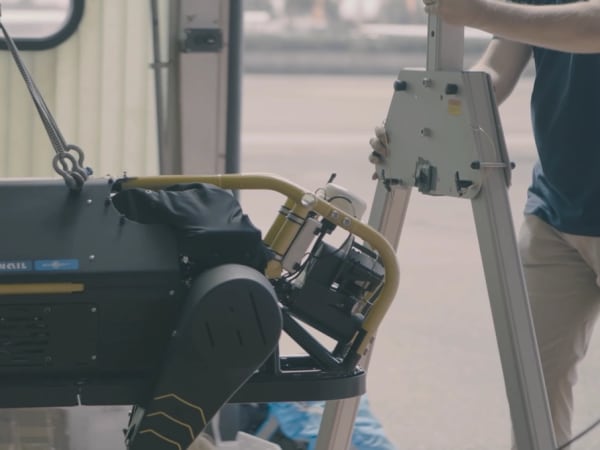
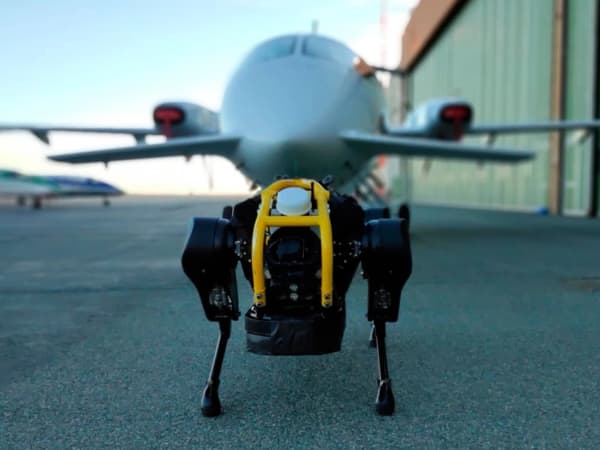
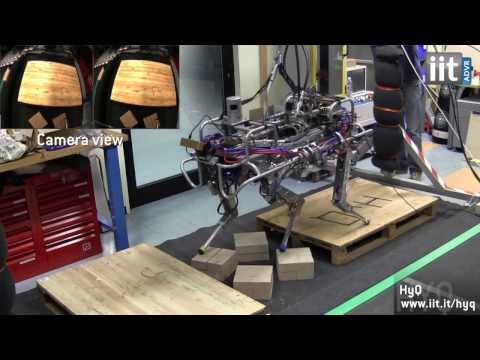
HyQReal is an advanced hydraulically actuated quadruped robot developed by the Italian Institute of Technology (IIT) in collaboration with Moog, representing an evolution of the HyQ and HyQ2Max platforms. Designed for real-world applications in challenging environments, it excels in rough terrain locomotion with capabilities including running, jumping, reflexes, and walking over uneven surfaces like stairs and rubble. Fully power-autonomous with onboard batteries, hydraulics, and wireless communication, HyQReal demonstrates exceptional strength, such as pulling a 3-ton airplane over 10 meters. Protected by an aluminum roll cage and Kevlar-glass fiber-plastic skin, it targets disaster response, inspection, agriculture, decommissioning, and other tasks in dangerous, dirty, or unstructured settings where wheeled vehicles fail. Key enhancements include higher ruggedness, reliability, energy efficiency, and intelligent teleoperation algorithms for superior mobility.
What Can HyQReal Do?
Core operational tasks and activities demonstrated or performed by HyQReal.
Real-World Applications of HyQReal
Industries, working environments, and deployment suitability for HyQReal.
HyQReal Capabilities
Inherent physical, perceptual, and cognitive abilities built into HyQReal.
Image Gallery
Below images are from Italian Institute of Technology (IIT)'s official sources
Review Videos
Watch expert reviews and demonstrations of this robot dog
Full Specifications
Other Notable Features
custom rubber feet for high traction, torque/load sensors, absolute position sensors (19-bit), joint control at 5kHz torque/1kHz position
More Robots from Italian Institute of Technology (IIT)
Explore other robots and developments from this manufacturer
iRonCub
Manufactured by Italian Institute of Technology (IIT)
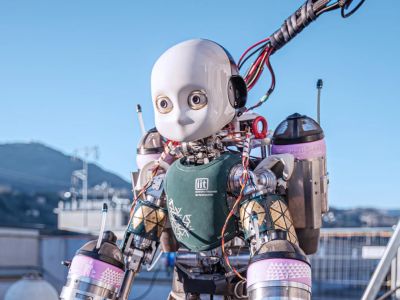
iRonCub is a groundbreaking jet-powered flying humanoid robot developed by IIT's AMI lab, transforming the iCub3 platform into the world's first humanoid capable of controlled flight. Equipped with four micro-jet engines—two on the arms and two on a backpack jetpack—it generates over 1000 Newtons of thrust to achieve stable hover up to 50 cm, managing extreme heat over 800°C via a titanium spine and heat-resistant covers. Advanced AI control systems, including neural networks and UKF pose estimation, enable human-like balance amid turbulent airflows, shifting center of mass, and limb movements. Onboard sensors like IMU and depth cameras support real-time flight dynamics, multibody aerodynamics, and non-stationary maneuvers. Designed for research in aerial humanoid robotics, it pioneers applications in search-and-rescue, hazardous inspections, and disaster response, blending bipedal morphology with unprecedented aerial agility.
Frequently Asked Questions
Get answers to common questions about this robot