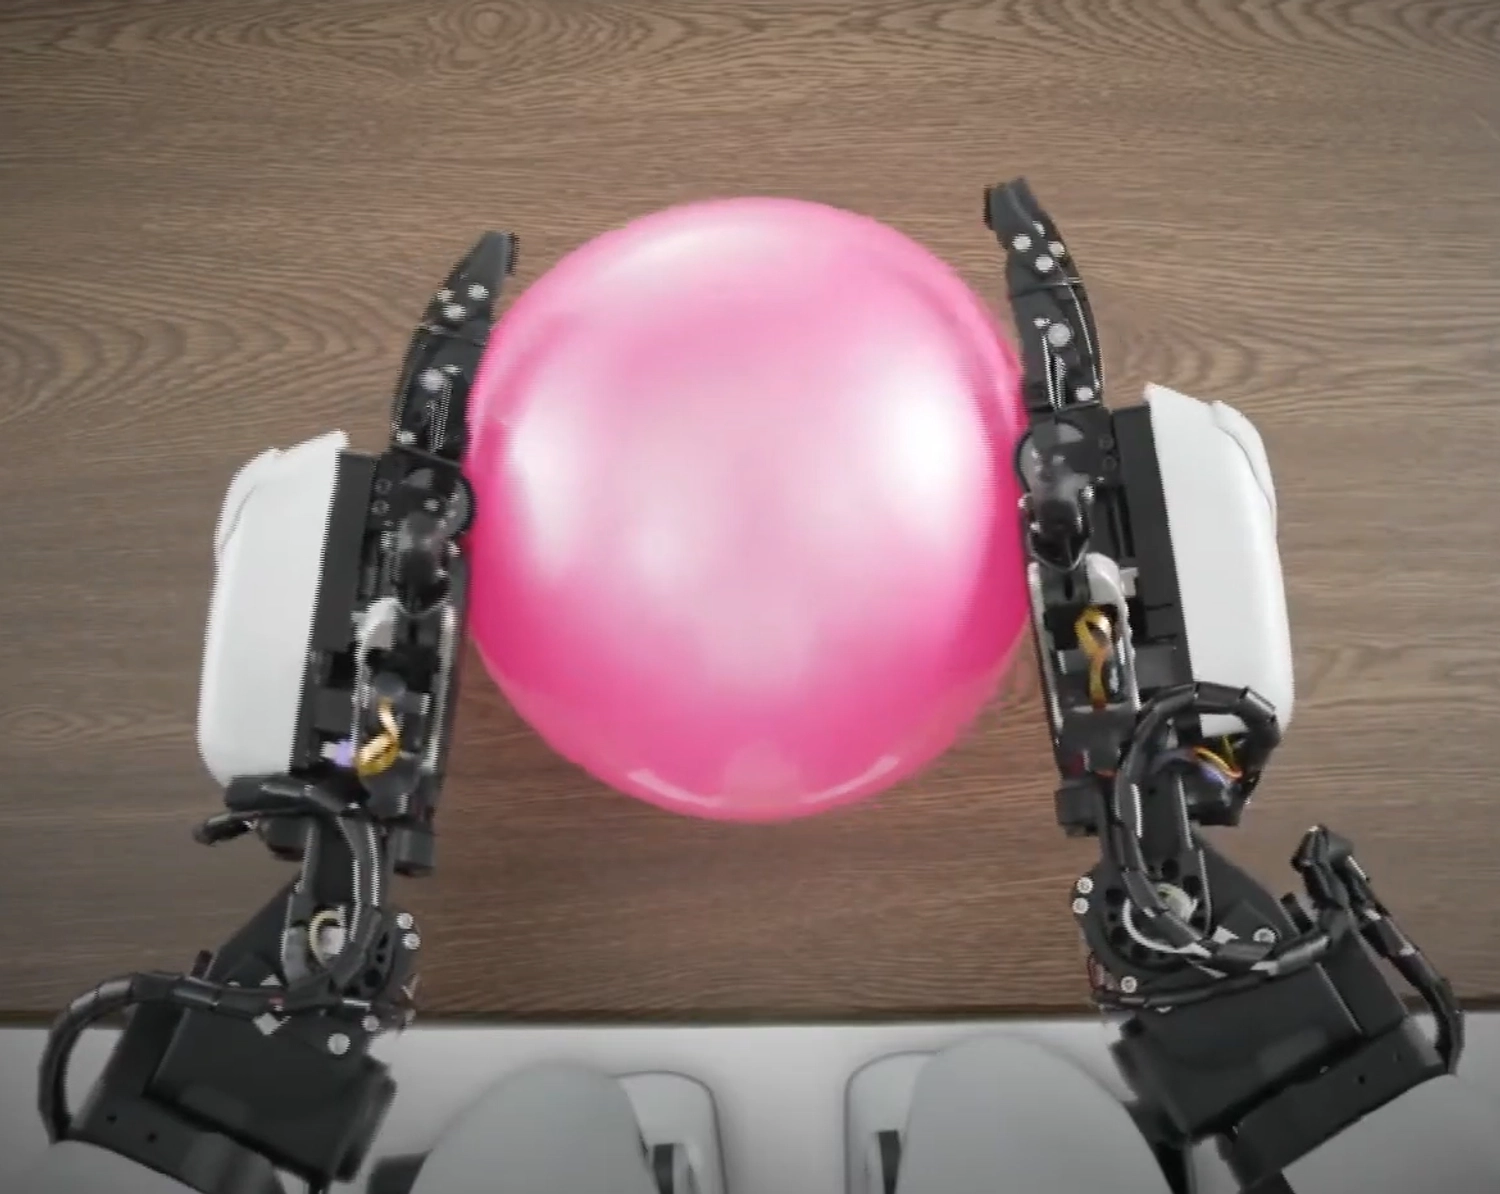
Toyota T-HR3 Hand
AI ChatLast updated:
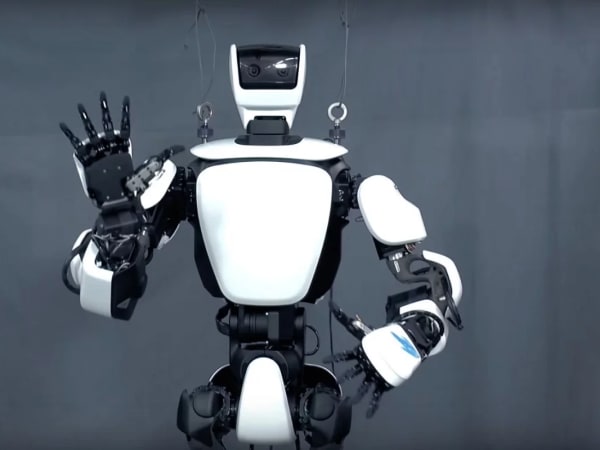
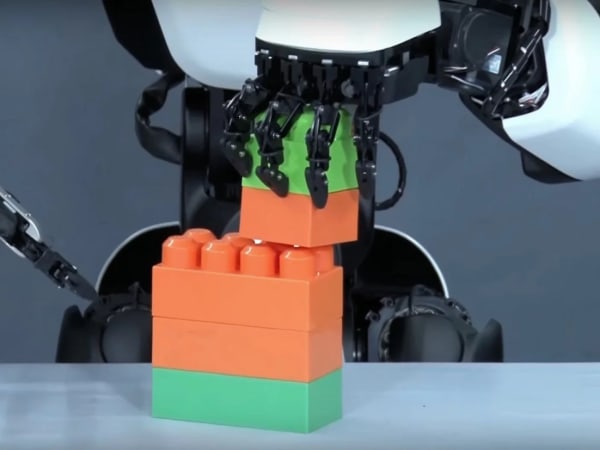
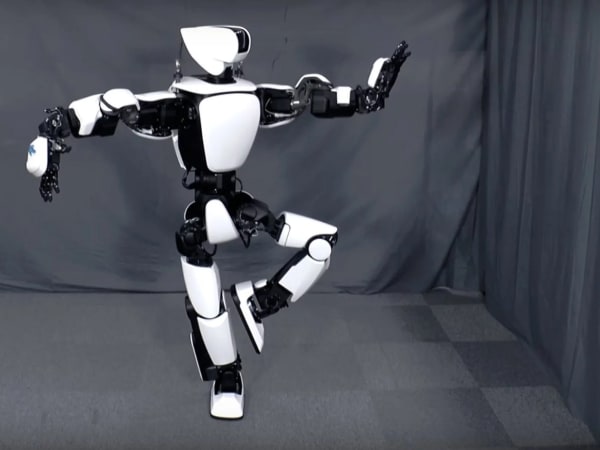
The Toyota T-HR3 Hand is a five-fingered dexterous end-effector integrated into the T-HR3 third-generation humanoid robot, designed for safe human-robot interaction and precise remote manipulation. It features torque-controlled degrees of freedom via Torque Servo Modules, enabling delicate tasks like coin picking, force feedback, and teleoperation through a Master Maneuvering System with haptic synchronization. Targeted for homes, healthcare, construction, and disaster response, it emphasizes flexible joint control and whole-body coordination.
Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by Toyota: EMC compliance, noise level, expected lifespan, maintenance schedule, firmware version, update method, hardware ports, color options and 4 more.
Image Gallery
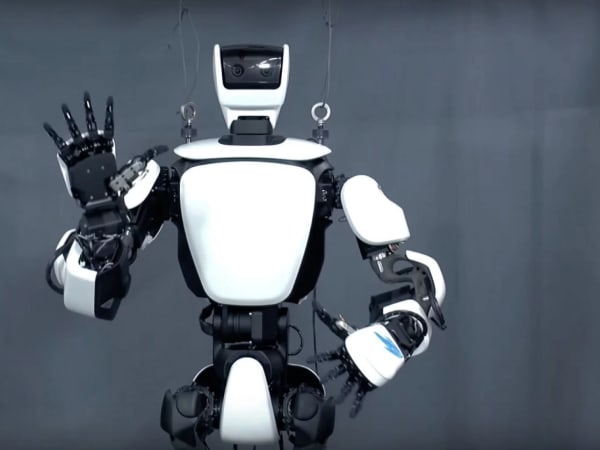
Below images are from Toyota's official sources
Review Videos
Watch expert reviews and demonstrations of this robot
Toyota T-HR3 Hand vs Revo 3 Dexterous Hand, Shuqiao X2 Adaptive Hand and Clone Hand
Toyota T-HR3 Hand trails the closest alternatives on degrees of freedom, weight, max payload, power grip force and closing time, so it is better judged by how well it fits teleoperation.
Green marks the best figure in a row (highest degrees of freedom, max payload and power grip force; lowest weight and closing time). Ranges are not ranked.
| Spec | Toyota T-HR3 HandToyota | Revo 3 Dexterous HandBrainCo | Shuqiao X2 Adaptive HandChangingTek Robotics | Clone HandClone Robotics |
|---|---|---|---|---|
| Degrees of Freedom | 5 | 21 | 16 | 27 |
| Weight | 750 g | 430 g | 1.2 kg | 750 g |
| Max Payload | 500 g | 20 kg | 5 kg | 7 kg |
| Power Grip Force | 40 N | 100 N | 50 N | 66 N |
| Closing Time | 300 ms | 330 ms | — | 100 ms |
| Hand Type | anthropomorphic | anthropomorphic | anthropomorphic | anthropomorphic |
| Fingers | 5 | 5 | 5 | 5 |
| Best For | Teleoperation | Humanoid manipulation | Insertion | Teleoperation |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all humanoid robot hands
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is the humanoid robot hand Toyota T-HR3 Hand, and what problem does it solve?
The Toyota T-HR3 Hand is the hand component of Toyota's T-HR3 humanoid robot, launched in 2017. According to Toyota, it addresses mobility challenges by enabling remote assistance in settings like homes and medical facilities through force-sharing technology.
Q2. What are the main capabilities and key features of Toyota T-HR3 Hand?
The T-HR3 Hand features dexterous finger movements controlled via a Master Hand in the Master Maneuvering System. Toyota states it supports force feedback and torque servo modules for smooth, synchronized operation mirroring human actions.
Q3. Which industries and use cases is Toyota T-HR3 Hand built for?
Toyota developed the T-HR3 Hand for applications in homes, healthcare, construction, disaster response, and space. The company aims for it to assist humans safely in varied environments via remote control.
Q4. What is the grip strength and dexterity of Toyota T-HR3 Hand?
According to Toyota, the T-HR3 Hand provides dexterity for delicate tasks like picking up coins, with torque control enabling gentle grips. Specific strength metrics are not publicly detailed by the manufacturer.
Q5. Is Toyota T-HR3 Hand compatible with standard robotic arms?
Toyota has not specified compatibility with standard robotic arms. The T-HR3 Hand integrates with the T-HR3 robot's Torque Servo Modules and Master Maneuvering System for full-body control.
Q6. Does Toyota T-HR3 Hand support tactile sensing or force feedback?
Yes, the T-HR3 Hand supports force feedback through torque sensors in its servo modules. Toyota indicates this allows operators to sense forces exerted on the robot during interactions.
Q7. What programming interfaces or SDKs are available for Toyota T-HR3 Hand?
Toyota has not publicly detailed programming interfaces or SDKs for the T-HR3 Hand. Control occurs via the proprietary Master Maneuvering System with wearable inputs.
Q8. How does Toyota T-HR3 Hand compare to other robotic end-effectors?
Toyota positions the T-HR3 Hand as advancing from prior instrument-playing robots to force-sharing dexterity. Direct comparisons to other end-effectors are not provided by the company.
Q9. What level of maintenance is required for Toyota T-HR3 Hand?
Maintenance details for the T-HR3 Hand are not specified by Toyota. The design uses torque servo modules at joints, intended for reliable remote operation in research contexts.
Q10. Is Toyota T-HR3 Hand currently available for commercial purchase?
No, the T-HR3 Hand is part of Toyota's research platform launched in 2017. The company has not announced commercial availability as of the latest updates.
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.