RoboParty
RoboParty is a Shanghai humanoid robot start-up founded in 2025 by Yi Huang, a 21-year-old roboticist who previously built the open-source AlexBot humanoid in his university dormitory at the Harbin Institute of Technology on a budget of about US$2,100. In November 2025 it closed a US$10 million seed round led by Matrix Partners China and Xiaomi Strategic Investment, with backing from Galbot and the L2F Light Source Entrepreneurs Fund. Its ROBOTO ORIGIN is a full-stack, open-source bipedal humanoid, 1.25 m tall and 34 kg, that runs at up to 3 m/s using RoboParty's self-developed AMP anthropomorphic gait algorithm. Development took 120 days between April and August 2025, and the hardware designs, control code and documentation were open-sourced on GitHub in January 2026, gaining more than 1,000 stars. RoboParty launched the ORIGIN publicly on 12 February 2026. Huang calls the robot a problem validator for democratising embodied AI infrastructure.
💡Notable Achievement: Built its first humanoid prototype in about 120 days and open-sourced structure, electronics, training and deployment code.
What Does RoboParty Do?
RoboParty is a Shanghai, Xiaomi-backed startup that open-sources full-stack humanoids, starting with the ROBOTO ORIGIN prototype (RoboHead).
“Open-source hardware and code for anyone to build a humanoid.”
Full-Stack Open Source
Structure, electronics, training and deployment code released.
Fast Development
First prototype built in about 120 days.
Strategic Backers
Seed round from MPCi, Xiaomi Strategic Investment and Galbot.
What Can RoboParty Robots Actually Do?
Cross-portfolio operational capabilities, manipulation tasks, and environmental competencies
An affordable open humanoid for learning, research and makers.
Open Hardware & Code
Complete open-source release for builders.
AMP Gait Running
Runs at about 3 m/s with the AMP gait algorithm.
Sim-to-Real Education
ROS 2 Humble, Isaac Sim and Isaac Lab workflows.
US$7,000 Price Point
Affordable entry for research.
RoboParty Robots
Showing 2 Humanoid Robots of 2 total models

RP1
By: RoboParty
Launched: 2026
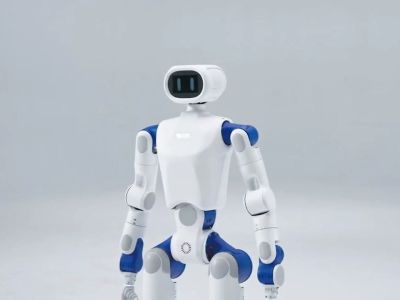
RP1 (also called ROBOTO 01) is a full-size bipedal humanoid robot from RoboParty, the Shanghai team behind the open-source ROBOTO Origin project. It debuted at IROS 2026 in Pittsburgh on September 28, 2026, where visitors were invited to push and kick it in a "Kick Me" demo to show how quickly it recovers its balance and gets back up after a fall. RP1 stands 1.35 m tall and weighs about 39 kg. It has 24 active degrees of freedom, or 30 on the RP1 Pro, and runs on RoboParty's own Romomo joint modules with up to 160 N·m of peak torque. It can run at up to 4 m/s, climb 30° slopes, carry 5 kg per arm and work for about 3 hours on a hot-swappable 10 Ah battery. What sets it apart is that it is open source end to end: RoboParty publishes the structure drawings, bill of materials, PCBs and 3D models, as well as the drivers, gait algorithms, ROS 2 middleware, SDK, simulation and training code. Swappable heads and hands let one robot serve motion-control, perception, data-collection or interaction work. RP1 is built for researchers, universities and embodied-AI teams.
ROBOTO ORIGIN
By: RoboParty
Launched: 2025
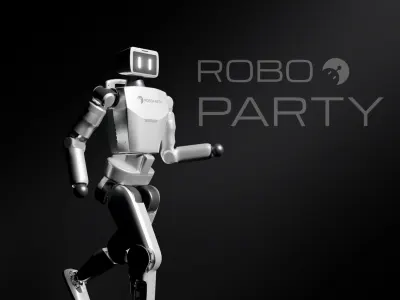
ROBOTO ORIGIN is RoboParty's fully open-source bipedal humanoid prototype, also released as RoboHead (hardware ATOM 01). About 1.25 m tall and 34 kg, it was designed and built in roughly four months in 2025, then open-sourced in January 2026 with structure drawings, BOM, electronics, RL training and deployment code. It can run at about 3 m/s using RoboParty's AMP gait algorithm, and its full bill of materials totals $7,000 (about ¥49,713).
RoboParty Software & AI Ecosystem
Developer platforms, fleet management portals, autonomy intelligence, and enterprise integrations
Isaac Lab RL Pipeline
Sim-to-Real Training
Isaac Sim 4.5 / Isaac Lab 2.1 policies.
ROS 2 Humble
Python & C++
ROS 2 Humble on Linux.
RoboParty Timeline & Milestones
Evolutionary history, landmark prototypes, major acquisitions, and commercial roadmap
$10 million seed round
RoboParty closes a US$10 million seed round led by Matrix Partners China and Xiaomi Strategic Investment, with Galbot participating.
Source: globenewswire.com
ROBOTO ORIGIN open-sourced
RoboParty open-sources ROBOTO ORIGIN, releasing hardware designs, control code and documentation on GitHub.
Source: globenewswire.com
ORIGIN humanoid launched
RoboParty launches ORIGIN, a 1.25 m, 34 kg full-stack open-source bipedal humanoid that runs at up to 3 m/s.
Source: globenewswire.com
RoboParty Competitors by Category
Direct industry rivals grouped by specific robotics domain
What Makes RoboParty Different?
Editorial AnalysisOrigin of Bots objective strategic assessment, engineering moats, and commercial hurdles
Key Strengths & Moats
- ✓Fully open-source approach lowers barriers.
- ✓Xiaomi and Galbot backing.
- ✓Competitive US$7,000 price.
Core Strategic Focus
Building a developer community around open humanoids.
Road Ahead & Challenges
- •Monetisation beyond hardware sales is unproven.
- •About 1 hour of runtime.
RoboParty vs Key Competitors
Strategic capability matrix across platform categories, commercial readiness, and target markets
Category / Focus
- RoboParty
- Bipedal Humanoid
- Unitree Robotics Unitree G1
- Low-cost research humanoid
- Booster Robotics K1 Humanoid
- Compact developer humanoid
- Noetix Robotics E1
- Compact research humanoid
- EngineAI Robotics PM01
- Compact dynamic research humanoid
Primary Use
- RoboParty
- Learning humanoid robotics
- Unitree Robotics Unitree G1
- High-speed bipedal running, 360° ground recovery
- Booster Robotics K1 Humanoid
- Education, research
- Noetix Robotics E1
- Not listed
- EngineAI Robotics PM01
- Dynamic terrain running, jumping
Weight
- RoboParty
- 34 kg
- Unitree Robotics Unitree G1
- 35 kg
- Booster Robotics K1 Humanoid
- 19.5 kg
- Noetix Robotics E1
- 36 kg
- EngineAI Robotics PM01
- 40 kg
Battery Runtime
- RoboParty
- 1 h
- Unitree Robotics Unitree G1
- 2 h
- Booster Robotics K1 Humanoid
- N/A
- Noetix Robotics E1
- 1–2 h
- EngineAI Robotics PM01
- 2 h
| Strategic Dimension | RoboParty(Current) | Unitree Robotics Unitree G1 | Booster Robotics K1 Humanoid | Noetix Robotics E1 | EngineAI Robotics PM01 |
|---|---|---|---|---|---|
| Category / Focus | Bipedal Humanoid | Low-cost research humanoid | Compact developer humanoid | Compact research humanoid | Compact dynamic research humanoid |
| Primary Use | Learning humanoid robotics | High-speed bipedal running, 360° ground recovery | Education, research | Not listed | Dynamic terrain running, jumping |
| Weight | 34 kg | 35 kg | 19.5 kg | 36 kg | 40 kg |
| Battery Runtime | 1 h | 2 h | N/A | 1–2 h | 2 h |
Corporate Ecosystem & Ownership Structure
Parent company relationships, historical acquisitions, and global operating facilities
Xiaomi Strategic Investment
Participated in RoboParty's seed round.
Ownership & Acquisition History
Participated in RoboParty's seed round.
Global Facilities & Operating Hubs
RoboParty Headquarters
HQShanghai, China
Articles & Industry News
Showing 1 recent article and news updates about RoboParty
Frequently Asked Questions
8 AnswersVerified answers, company specifications, and deployment details about RoboParty
What is RoboParty?
RoboParty is a Shanghai humanoid robot start-up, founded in 2025, that makes the open-source ROBOTO ORIGIN bipedal humanoid and is backed by Xiaomi and Matrix Partners China.
Who founded RoboParty?
RoboParty was founded by Yi Huang, a 21-year-old roboticist who earlier built the open-source AlexBot humanoid as a first-year student at the Harbin Institute of Technology.
What is ROBOTO ORIGIN?
ROBOTO ORIGIN is a full-stack open-source bipedal humanoid, 1.25 m tall and 34 kg, that runs at up to 3 m/s using RoboParty's AMP anthropomorphic gait algorithm.
Is ROBOTO ORIGIN open source?
Yes. RoboParty published ORIGIN's full hardware designs, control code and engineering documentation on GitHub in January 2026, and it gathered more than 1,000 stars.
How much has RoboParty raised?
RoboParty closed a US$10 million seed round in November 2025, led by Matrix Partners China and Xiaomi Strategic Investment, with Galbot and the L2F fund taking part.
How fast was ORIGIN developed?
ROBOTO ORIGIN was developed in 120 days between April and August 2025, and RoboParty launched it publicly on 12 February 2026.
Who is ORIGIN for?
RoboParty calls ORIGIN a problem validator for democratising embodied AI infrastructure, aimed at developers and researchers who want a full open humanoid to build on.
How much does ROBOTO ORIGIN cost?
RoboParty has not published a price for ORIGIN in the launch announcement. Its designs are open, so builders can also source parts and assemble it themselves.
Verified Data & Editorial Assurance
Compiled from verified corporate filings, official RoboParty datasheets, and robotics engineering registries. Data is monitored and audited on an ongoing basis for accuracy. For commercial procurement or proprietary integrations, contact the manufacturer directly.