NASA Details Valkyrie Humanoid's Role in Lunar Logistics and Harsh Environment Robotics Testing
Robot Details
Robotics & AI News • OriginOfBotsPublished
September 29, 2026
Reading Time
6 min read
Author
Origin Of Bots Editorial Team
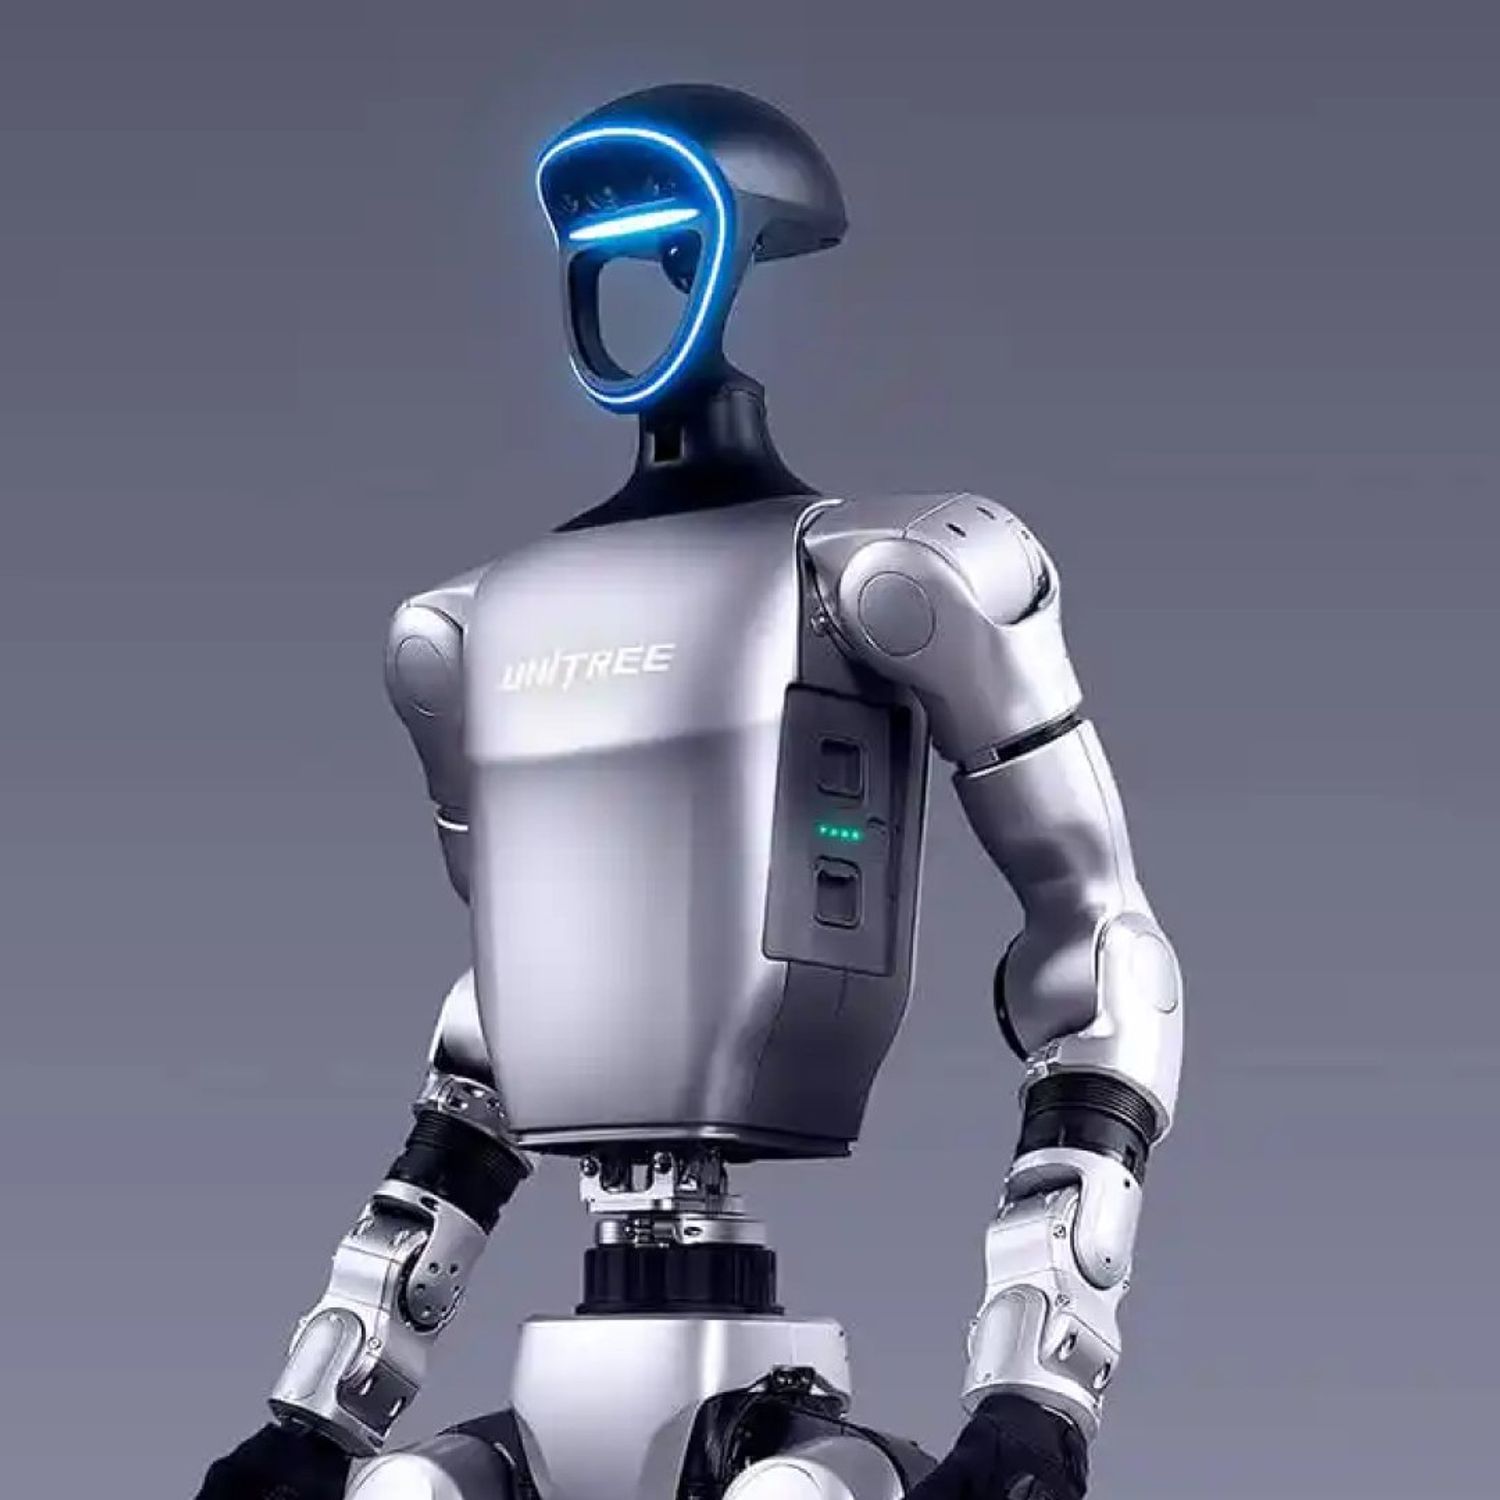
Operational Mandate of the Johnson Space Center Dexterous Robotics Team
NASA's specialized Dexterous Robotics Team, operating out of the Johnson Space Center in Houston, Texas, has formally detailed how years of empirical research with the Valkyrie humanoid are actively shaping future lunar exploration architectures. Comprising a dedicated sixteen-person interdisciplinary engineering unit, the group focuses on developing physical and computational robotics stacks tailored to operate within environments built for human beings.
Rather than seeking to displace human astronauts on the Moon, the team's central objective is engineering trustworthy autonomous agents capable of performing dangerous preparatory setup and high-strain maintenance. By deploying robust humanoid systems into harsh extraterrestrial regimes ahead of astronaut arrival, NASA aims to dramatically improve crew safety, lower operational risk, and establish sustainable deep-space mission cadence.
The team brings together deep institutional expertise spanning precision mechatronics, advanced sensor fusion, high-fidelity kinematic simulation, and real-time control software. Many current members previously engineered critical subsystems for Robonaut 2, which demonstrated dexterous manipulation aboard the International Space Station for more than seven years, providing foundational insight into long-duration space robotics.
Architectural Evolution from Robonaut 2 to Bipedal Valkyrie
The operational transition from upper-body telepresence platforms to full bipedal architectures represents a major milestone in NASA's robotics roadmap. Valkyrie, recognized as the space agency's first full-scale bipedal humanoid robot, was engineered with human-like physical dimensions to allow direct interaction with tools, airlocks, and hatches designed for spacesuited astronauts.
Standing over six feet tall and weighing approximately 300 pounds, Valkyrie features a sensor-rich perception head, multi-axis force-torque sensing wrists, and compliant linear actuators embedded throughout its limbs. This high-degree-of-freedom chassis allows the machine to adjust its posture dynamically, counterbalancing shifting loads while manipulating heavy cargo parcels in variable gravity environments.
By analyzing historical telemetry from Valkyrie's extensive laboratory trials, engineers have mapped out the mechanical fatigue profiles, thermal tolerances, and power bottlenecks inherent to humanoid mechanisms. These findings now provide foundational design criteria for the next generation of spaceflight-qualified robotic manipulators destined for deployment on the lunar surface.
Simulating Astronaut Workflows and Autonomous Cargo Handling
Recent operational testing conducted by the Dexterous Robotics Team has focused heavily on autonomous and supervisory cargo handling routines, simulating the unloading of pressurized logistics modules. In representative laboratory trials, Valkyrie successfully demonstrated the multi-point grasping, lifting, and secure transit of densely packed duffel bags weighing up to forty pounds.
Handling compliant, non-rigid cargo such as soft storage bags introduces complex manipulation challenges because the center of mass shifts unpredictably during transport. Valkyrie's whole-body control algorithms continuously modulate joint impedance, dynamically redistributing ground reaction forces across its feet to prevent slipping or losing dynamic equilibrium.
These logistics demonstrations validate that humanoid form factors can reliably transfer equipment from cargo landers to habitat vestibules without requiring custom crane fixtures. As a result, future lunar supply missions can maximize usable scientific payload mass by relying on general-purpose humanoids for unpacking and site preparation.
The iMETRO Testbed as an Integrated Lunar Proving Ground
A cornerstone of NASA's testing methodology is the Integrated Mobile Evaluation Testbed for Robotics Operations, known as iMETRO, housed at Johnson Space Center. This advanced evaluation facility unites open-source robotic middleware, photorealistic digital twins, high-fidelity spacecraft mockups, and an expansive outdoor rock yard mimicking lunar regolith topography.
The iMETRO architecture allows research teams to evaluate complete robotic prototypes end-to-end or isolate specific hardware sub-assemblies for targeted qualification stress testing. Engineers can subject experimental vision sensors, tactile end-effectors, and motor drives to abrasive dust, uneven slopes, and harsh directional lighting reminiscent of the lunar south pole.
Crucially, the facility provides an open collaborative testbed where commercial robotics startups, academic laboratories, and international space agencies can validate their systems against standardized spaceflight tasks. This common proving ground drastically accelerates the maturation of embodied AI algorithms prior to formal flight certification.
Hardware-in-the-Loop Evaluation Across Habitat and Hatch Mockups
Within the iMETRO testing complex, NASA has established rigorous hardware-in-the-loop protocols evaluating robotic interactions with full-scale architectural mockups. In a prominent collaborative trial highlighted by the agency, software developed by PickNik Robotics enabled an autonomous robotic manipulator to identify a pressurized spacecraft hatch, rotate its mechanical latch, pull the heavy hatch open, and transfer cargo containers through the portal.
In a parallel maintenance experiment, a student engineering cohort integrated commercial depth cameras with a multi-jointed arm to execute automated inspection and maintenance cycles on a deep-freeze science storage locker. The robot successfully opened the thermal door, inventoried biological sample vials using visual barcodes, and resealed the freezer latch within stringent thermal loss tolerances.
While these specific evaluations utilized modular manipulator arms, the underlying computer vision algorithms, motion planners, and tactile feedback loops transfer directly to Valkyrie-class bipedal platforms. Mastering these delicate mechanical interactions proves that robotic assistants can reliably service complex life-support infrastructure when human crews are absent.
Morphological Adaptations for Human-Centric Space Architecture
NASA's testing at iMETRO has yielded invaluable reciprocal design insights for both roboticists and human habitat architects. By systematically cataloging where Valkyrie encounters physical manipulation constraints, engineers can recommend ergonomic modifications to future lunar module interiors, such as enlarging manual hatch levers and repositioning interior guide rails.
Slight modifications to ambient lighting arrays and high-contrast fiducial markers on habitat panels have been shown to dramatically decrease robotic perception errors while simultaneously aiding visibility for human crew members wearing tinted helmet visors. This symbiotic design approach ensures that extraterrestrial habitats are natively optimized for seamless human-robot cooperation.
Furthermore, the shared spatial requirements of human astronauts and humanoid robots eliminate the need for redundant access corridors or specialized mechanical docking interfaces. Habitats, rovers, and maintenance airlocks can be engineered around a single universal set of anthropomorphic dimensions, maximizing usable interior volume.
Cross-Pollination with Terrestrial Extreme-Environment Industries
The extreme engineering demands of lunar exploration have fostered direct cross-pollination between NASA's humanoid robotics program and terrestrial heavy industries. The Johnson Space Center team actively collaborates with commercial offshore energy and subsea infrastructure operators facing hazardous remote maintenance challenges.
Terrestrial energy operators are increasingly seeking to deploy dexterous robotic caretakers to uncrewed offshore oil and gas drilling platforms to manage routine inspections and valve operations in corrosive marine environments. Technologies refined on Valkyrie—including radiation-tolerant control electronics, modular joint seals, and low-latency supervisory teleoperation links—are finding direct commercial utility in remote industrial sites.
This dual-use technology pipeline ensures that taxpayer-funded space robotics research generates tangible economic benefits on Earth. Simultaneously, continuous operational feedback from offshore commercial deployments provides NASA engineers with extensive endurance data, identifying mechanical wear points that inform lunar hardware revisions.
Long-Term Trajectory Toward Artemis Base Camp Autonomy
Looking ahead to the upcoming phases of the Artemis program, NASA envisions autonomous humanoid robots serving as permanent caretakers of the Artemis Base Camp on the lunar surface. During the long dormant periods between crewed surface missions, humanoid fleets will oversee power generation arrays, clear regolith dust from solar panels, and prepare science experiments.
By the time astronauts touch down for subsequent surface expeditions, robotic caretakers will have validated environmental life-support systems, checked rover battery banks, and staged necessary exploration gear. This proactive logistical cadence transforms human surface stays from grueling maintenance survival missions into highly productive scientific expeditions.
NASA's ongoing work with Valkyrie demonstrates that the path to sustainable planetary exploration relies on merging human scientific judgment with tireless robotic physical capability. The foundational control architectures honed inside Johnson Space Center's testing bays are laying the physical infrastructure for humanity's permanent expansion into deep space.
Related Articles
Boston Dynamics Opens Robotics Metaplant Application Center to Train Atlas Humanoid Fleet for Hyundai Manufacturing
Intel Unveils Open Edge Infrastructure Strategy to Scale Physical AI and Humanoid Robotics
Saudi Arabia and Humanoid AI Form Strategic Partnership for Up to 10,000 Humanoid Robots Under Vision 2030
Agility Robotics Explores Wheeled Humanoid Variants to Complement Bipedal Digit Fleet
Learn More About This Robot
Discover detailed specifications, reviews, and comparisons for Robotics & AI News.
View Robot Details →