ETH Zurich (Robotic Systems Lab)
The Robotic Systems Lab (RSL) at ETH Zurich is led by Professor Marco Hutter, who has been assistant professor of robotic systems at ETH since 2015. It is known for legged robots that walk over rough terrain, and its ANYmal quadruped was spun out in 2016 as the company ANYbotics. RSL also developed Magnecko, a quadrupedal magnetic climbing robot built as a research platform for legged climbing, aimed at industrial inspection and maintenance in hard-to-reach places. A separate ETH group, the Soft Robotics Lab under Robert Katzschmann, created the ORCA Hand, a tendon-driven anthropomorphic hand with 17 degrees of freedom, integrated tactile sensors and joints that safely pop out under overload. Its material cost is below 2,000 Swiss francs, it takes under eight hours to assemble, and all designs and software are open source.
💡Notable Achievement: ETH Zurich's open-source ORCA Hand has 17 degrees of freedom and a material cost below 2,000 Swiss francs.
What Does ETH Zurich (Robotic Systems Lab) Do?
ETH Zurich's Robotic Systems Lab, led by Marco Hutter, builds legged and mobile robots, gave rise to ANYbotics, and shares a campus with the Soft Robotics Lab behind the open-source ORCA Hand.
“Where the ANYmal quadruped began.”
Legged Robots
ANYmal research led to spin-off ANYbotics in 2016.
Magnecko
Quadruped magnetic climbing robot for industrial inspection.
ORCA Hand
Open-source 17-DOF tendon-driven hand from the Soft Robotics Lab.
What Can ETH Zurich (Robotic Systems Lab) Robots Actually Do?
Cross-portfolio operational capabilities, manipulation tasks, and environmental competencies
Legged climbing and dexterous hand research.
Climbing Inspection
Magnecko climbs steel structures on magnetic feet.
Open-Source Hand
ORCA is a low-cost, sensorized, tendon-driven hand.
ETH Zurich (Robotic Systems Lab) Robots & Robot Hands
Showing 2 of 2 total models
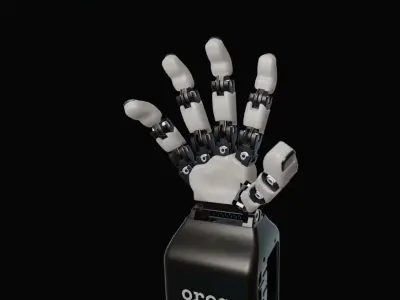
ORCA Hand
By: ETH Zurich (Robotic Systems Lab)
Launched: 2025
The ORCA Hand is an open-source, tendon-driven, anthropomorphic robotic hand with 17 degrees of freedom, including an opposable thumb and actuated wrist, designed for human-like dexterity. It features integrated tactile sensors on all fingertips, popping joints for quick assembly (<8 hours), auto-calibration, and tensioning systems for reliability. Built for under 2,000 CHF in materials, it supports teleoperation, imitation learning, and sim-to-real RL, with proven durability over 10,000 cycles (~20 hours).
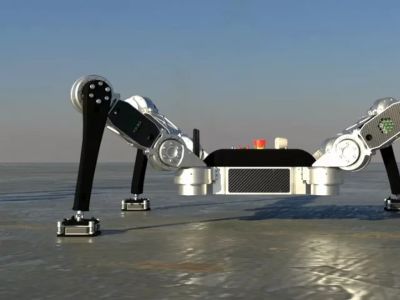
Magnecko
By: ETH Zurich (Robotic Systems Lab)
Launched: 2024
Magnecko is a quadrupedal magnetic climbing robot designed for industrial inspection and maintenance in hard-to-reach environments. The robot features four identical legs with insect-style joint configuration and electro-permanent magnetic feet that enable adhesion to ferrous surfaces in any orientation, including vertical walls and horizontal overhangs. With 12 actuated degrees of freedom and high manipulability, Magnecko can traverse complex three-dimensional environments, overcome concave 90° corners, and carry payloads up to 65% of its own weight. Primary applications include inspection of industrial tanks, ship hulls, bridges, and tall metal structures where human access is hazardous or difficult.
ETH Zurich (Robotic Systems Lab) Timeline & Milestones
Evolutionary history, landmark prototypes, major acquisitions, and commercial roadmap
ANYbotics spun out of RSL
Robotics researchers from ETH Zurich's Robotic Systems Lab found ANYbotics to commercialise the ANYmal legged robot.
Source: en.wikipedia.org
ORCA Hand published as open source
ETH Zurich's Soft Robotics Lab releases the ORCA Hand, a 17-degree-of-freedom tendon-driven hand with open designs and a material cost below 2,000 francs.
Source: srl.ethz.ch
ETH Zurich (Robotic Systems Lab) Competitors by Category
Direct industry rivals grouped by specific robotics domain
What Makes ETH Zurich (Robotic Systems Lab) Different?
Editorial AnalysisOrigin of Bots objective strategic assessment, engineering moats, and commercial hurdles
Key Strengths & Moats
- ✓Produced the technology behind ANYbotics.
- ✓Open-source hardware such as ORCA lowers the cost of dexterity research.
Core Strategic Focus
Legged robotics and soft, sensorized hands.
Road Ahead & Challenges
- •Research platforms, not commercial products.
- •The catalogue merges two ETH labs under one entry.
ETH Zurich (Robotic Systems Lab) vs Key Competitors
Strategic capability matrix across platform categories, commercial readiness, and target markets
Category / Focus
- ETH Magnecko
- Magnetic climbing quadruped
- ORCA Hand
- Open tendon-driven hand
- LEAP Hand V2
- Open low-cost hand
- EPFL Pleurobot
- Salamander research robot
Weight
- ETH Magnecko
- 11.3 kg
- ORCA Hand
- Not listed
- LEAP Hand V2
- Not listed
- EPFL Pleurobot
- 2.3 kg
Degrees of Freedom
- ETH Magnecko
- Not listed
- ORCA Hand
- 17 (16 in fingers + 1 in wrist)
- LEAP Hand V2
- 22 joints (17 Actuated / Motors)
- EPFL Pleurobot
- Not listed
Release Year
- ETH Magnecko
- 2024
- ORCA Hand
- 2025
- LEAP Hand V2
- 2024
- EPFL Pleurobot
- 2016
| Strategic Dimension | ETH Magnecko | ORCA Hand | LEAP Hand V2 | EPFL Pleurobot |
|---|---|---|---|---|
| Category / Focus | Magnetic climbing quadruped | Open tendon-driven hand | Open low-cost hand | Salamander research robot |
| Weight | 11.3 kg | Not listed | Not listed | 2.3 kg |
| Degrees of Freedom | Not listed | 17 (16 in fingers + 1 in wrist) | 22 joints (17 Actuated / Motors) | Not listed |
| Release Year | 2024 | 2025 | 2024 | 2016 |
Corporate Ecosystem & Ownership Structure
Parent company relationships, historical acquisitions, and global operating facilities
ANYbotics
Founded in 2016 to commercialise ANYmal.
Ownership & Acquisition History
Founded in 2016 to commercialise ANYmal.
Led by Robert Katzschmann; created the ORCA Hand.
Global Facilities & Operating Hubs
ETH Zurich (Robotic Systems Lab) Headquarters
HQZürich, Switzerland
Articles & Industry News
Showing 1 recent article and news updates about ETH Zurich (Robotic Systems Lab)
Frequently Asked Questions
8 AnswersVerified answers, company specifications, and deployment details about ETH Zurich (Robotic Systems Lab)
What is ETH Zurich's Robotic Systems Lab?
The Robotic Systems Lab (RSL) at ETH Zurich is a research group led by Marco Hutter that develops legged and mobile robots, including the ANYmal quadruped that led to ANYbotics.
Who leads the Robotic Systems Lab?
Marco Hutter has been assistant professor for robotic systems at ETH Zurich since 2015 and heads the Robotic Systems Lab.
What is Magnecko?
Magnecko is a quadrupedal magnetic climbing robot from ETH Zurich, built as a research platform for legged climbing locomotion in industrial inspection and maintenance.
What is the ORCA Hand?
ORCA is an open-source, tendon-driven anthropomorphic robotic hand from ETH Zurich's Soft Robotics Lab with 17 degrees of freedom, tactile sensing and auto-calibration.
How much does the ORCA Hand cost to build?
The ORCA Hand has a material cost below 2,000 Swiss francs, and it can be assembled in under eight hours from 3D-printed parts.
Who developed the ORCA Hand?
The ORCA Hand comes from ETH Zurich's Soft Robotics Lab, led by Robert Katzschmann, with lead authors Clemens Christoph, Maximilian Eberlein and Filippos Katsimalis.
How is RSL connected to ANYbotics?
ANYbotics, founded in 2016, is a spin-off from ETH Zurich's Robotic Systems Lab and sells the ANYmal inspection robot that grew out of its research.
Why does the ORCA Hand have poppable joints?
The ORCA Hand's poppable joints safely dislocate under excess load rather than break, which makes the hand durable and easy to repair.
Verified Data & Editorial Assurance
Compiled from verified corporate filings, official ETH Zurich (Robotic Systems Lab) datasheets, and robotics engineering registries. Information has been verified against official manufacturer documentation. For commercial procurement or proprietary integrations, contact the manufacturer directly.