TU Berlin
TU Berlin, the Technische Universität Berlin, is home to the Robotics and Biology Laboratory led by Professor Oliver Brock, and this entry covers its RBO Hand 3. The RBO Hand 3 is an anthropomorphic soft hand based on pneumatic actuation, built as a platform for soft dexterous manipulation. It has 16 independent degrees of actuation, implemented in a dexterous opposable thumb, two-chambered fingers, an actuated palm and the ability to spread the fingers. Its designers aimed to enable dexterous manipulation, to help transfer insights about human dexterity, and to serve as a robust research platform for extensive real-world experiments, by combining many degrees of actuation with intrinsic compliance and a modular design with robust components. The hand was described in a paper by Puhlmann, Harris and Brock in IEEE Transactions on Robotics in 2022, and TU Berlin published instructions for building your own RBO Hand 3. It is a research hand rather than a commercial product.
💡Notable Achievement: The RBO Hand 3 has 16 independent degrees of actuation driven pneumatically.
What Does TU Berlin Do?
TU Berlin's Robotics and Biology Laboratory, led by Oliver Brock, built the RBO Hand 3, a soft pneumatic hand for dexterous manipulation research.
“A soft, air-powered research hand.”
Soft Dexterity
Compliant pneumatic fingers and thumb.
16 Actuated DOF
Including an actuated palm.
Reproducible
Build instructions are published.
What Can TU Berlin Robots Actually Do?
Cross-portfolio operational capabilities, manipulation tasks, and environmental competencies
Soft manipulation research.
Soft Dexterous Hand
RBO Hand 3 handles objects with intrinsic compliance.
TU Berlin Robot Hands
Showing 1 of 1 total model
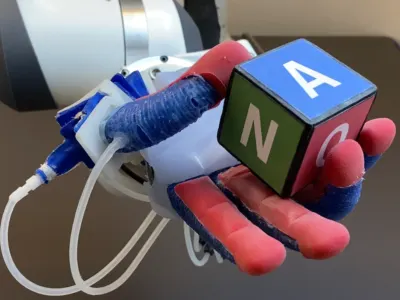
RBO Hand 3
Manufactured by TU Berlin
The RBO Hand 3 is a highly capable anthropomorphic soft hand developed by TU Berlin's Robotics and Biology Lab, featuring pneumatic actuation for dexterous manipulation. It combines 16 independent degrees of actuation with intrinsic compliance via two-chambered fingers, an opposable thumb, actuated palm, and finger spreading. Designed for real-world experiments, it replicates human hand functions, achieves top Kapandji thumb opposition scores, supports all 33 GRASP taxonomy types, and enables in-hand manipulation.
TU Berlin Timeline & Milestones
Evolutionary history, landmark prototypes, major acquisitions, and commercial roadmap
RBO Hand 3 paper published
Puhlmann, Harris and Brock publish the RBO Hand 3, a pneumatic anthropomorphic soft hand with 16 independent degrees of actuation for soft dexterous manipulation.
Source: arxiv.org
TU Berlin Competitors by Category
Direct industry rivals grouped by specific robotics domain
What Makes TU Berlin Different?
Editorial AnalysisOrigin of Bots objective strategic assessment, engineering moats, and commercial hurdles
Key Strengths & Moats
- ✓Well-documented soft hand design.
- ✓Strong soft robotics group.
Core Strategic Focus
Soft manipulation research.
Road Ahead & Challenges
- •Pneumatic hands need air supply.
- •Research platform only.
Corporate Ecosystem & Ownership Structure
Parent company relationships, historical acquisitions, and global operating facilities
Global Facilities & Operating Hubs
TU Berlin Headquarters
HQBerlin, Germany
Frequently Asked Questions
8 AnswersVerified answers, company specifications, and deployment details about TU Berlin
What is the RBO Hand 3?
The RBO Hand 3 is a pneumatically actuated anthropomorphic soft hand from TU Berlin with 16 independent degrees of actuation, built for research on soft dexterous manipulation.
Who developed the RBO Hand 3?
It was developed at the Robotics and Biology Laboratory of TU Berlin, led by Professor Oliver Brock, by researchers including Puhlmann and Harris.
How does the RBO Hand 3 move?
It uses pneumatic actuation, with an opposable thumb, two-chambered fingers, an actuated palm and the ability to spread the fingers, combining many degrees of actuation with intrinsic compliance.
Can I build an RBO Hand 3?
Yes. TU Berlin has published a guide called Building Your Own RBO Hand 3 so that other research labs can reproduce the soft hand.
Is the RBO Hand 3 a commercial product?
No. It is a research platform designed for real-world experiments in soft manipulation, not a product sold by TU Berlin.
Who leads the Robotics and Biology Laboratory?
Oliver Brock, Professor of Computer Science at Technische Universität Berlin, leads the Robotics and Biology Laboratory that developed the RBO Hand 3.
Why build a soft robot hand?
The designers wanted to transfer insights about human dexterity into a robust, compliant platform, since soft hands can grasp and manipulate in cluttered real-world settings.
Where is TU Berlin?
TU Berlin is in Berlin, Germany, and its catalogue record lists 1810 as the year of its earliest predecessor institutions.
Verified Data & Editorial Assurance
Compiled from verified corporate filings, official TU Berlin datasheets, and robotics engineering registries. Information has been verified against official manufacturer documentation. For commercial procurement or proprietary integrations, contact the manufacturer directly.