Wonik Robotics
Wonik Robotics is a South Korean robotics company in Seongnam, founded in 2004 by Kyong-Sok Chang and formerly known as SimLab, that develops robotics hardware and software control systems. It is best known for the Allegro Hand, a multi-fingered research robot hand commercialised under licence from technology developed by the Humanoid Robot Hand Research Group at the Korea Institute of Industrial Technology. The Allegro Hand V5 is a compact three-finger hand with a simple, robust nine degree-of-freedom structure for grasping and manipulation research, and Wonik has also released the V5 Plus, V5 Sense and older V4 models, and obtained CE certification for the V5 and V5 Plus. Wonik also delivered its Allegro Dog to the US Naval Research Laboratory. In October 2024 it partnered with Meta to build an advanced Allegro Hand with Meta's Digit Plexus tactile technology, which it planned to manufacture and distribute for researchers.
💡Notable Achievement: Wonik is developing an Allegro Hand with Meta's Digit Plexus tactile technology.
What Does Wonik Robotics Do?
Wonik Robotics makes the Allegro Hand, the widely used research robot hand, and is building a next version with Meta's tactile sensing.
“The default research hand for many labs.”
Allegro Hand
Nine-DoF three-finger hand.
Meta Partnership
Digit Plexus tactile version.
CE Certified
V5 and V5 Plus certified.
What Can Wonik Robotics Robots Actually Do?
Cross-portfolio operational capabilities, manipulation tasks, and environmental competencies
Research robot hands.
Grasping Research
Allegro Hand family for manipulation studies.
Wonik Robotics Robot Hands
Showing 4 of 4 total models
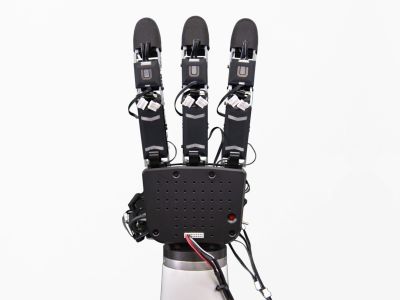
Allegro Hand V4
By: Wonik Robotics
Launched: 2024
The Allegro Hand V4 is a lightweight, dexterous robotic hand with 4 fingers and 16 independent torque-controlled joints, designed for advanced grasping, manipulation research, and robotics development. It supports real-time control via CAN at high frequency, enabling complex motions, learning-based control, and human-inspired grasping. Compact and adaptable for desktop or arm-mounted use, it facilitates studies in embodied AI, teleoperation, and dexterous manipulation without hardware setup burdens.
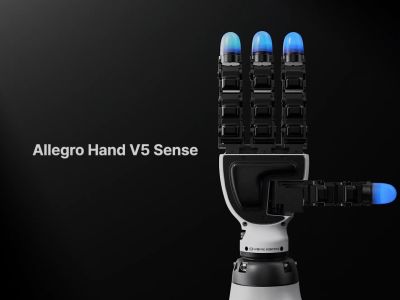
Allegro Hand V5 Sense
By: Wonik Robotics
Launched: 2025
The Allegro Hand V5 Sense is an advanced dexterous robotic hand by Wonik Robotics featuring 16 pressure sensors for precise tactile feedback and natural grasping capabilities. Equipped with adduction and abduction movements, it supports both CAN bus and Ethernet communication for reliable real-time control. Designed for research, education, and industrial applications requiring high-precision manipulation and haptic awareness.
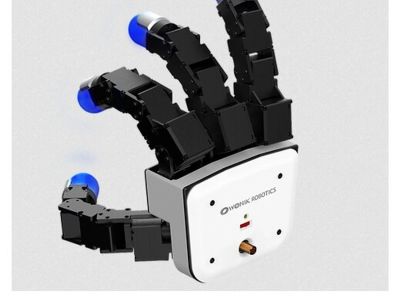
Allegro Hand V5 Plus
By: Wonik Robotics
Launched: 2025
The Allegro Hand V5 Plus is a highly dexterous, 4-finger robotic hand with 16 degrees of freedom, featuring independent current/torque-controlled joints for precise grasping and manipulation of diverse objects (rigid or soft). Designed for research, it supports real-time control, online simulation, and optional 360° pneumatic tactile fingertip sensors. Enhanced components enable stable handling up to 15 kg payload, with CAN communication at 500 Hz for advanced applications in robotics R&D and automation.
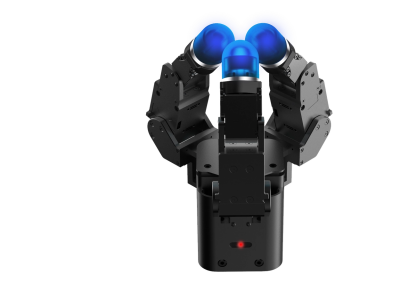
Allegro Hand V5
By: Wonik Robotics
Launched: 2025
The Allegro Hand V5 is a compact, torque-controlled robotic hand with 3-4 anthropomorphic fingers, designed for precise, compliant manipulation in research, education, and industrial applications. It features DC motor actuation, high-resolution joints, optional tactile sensors, and real-time CAN control at 500 Hz, supporting dexterous grasping of varied objects with payloads up to 12 kg depending on configuration and grasp type.
Wonik Robotics Timeline & Milestones
Evolutionary history, landmark prototypes, major acquisitions, and commercial roadmap
Wonik Robotics (SimLab) founded
Kyong-Sok Chang founds SimLab, later Wonik Robotics, to develop robotics hardware and software control systems.
Source: wonikrobotics.com
Meta partnership on Allegro Hand with Digit Plexus
Meta announces that Wonik Robotics will develop an advanced Allegro Hand incorporating Meta Digit Plexus tactile technology.
Source: ai.meta.com
Wonik Robotics Competitors by Category
Direct industry rivals grouped by specific robotics domain
Shadow Robot Company
→Model: Shadow Dexterous Hand
Focus: Research dexterous hands
Carnegie Mellon University
→Model: LEAP Hand V2
Focus: Open research hands
Schunk
→Model: Schunk SVH
Focus: Robot hands and grippers
TESOLLO
→Model: DG-5F-S
Focus: Dexterous humanoid hands
Inspire Robotics
→Model: RH56DFX
Focus: Dexterous hands
What Makes Wonik Robotics Different?
Editorial AnalysisOrigin of Bots objective strategic assessment, engineering moats, and commercial hurdles
Key Strengths & Moats
- ✓Widely used in research papers.
- ✓Meta collaboration.
Core Strategic Focus
Tactile Allegro Hand.
Road Ahead & Challenges
- •Cheaper open hands like LEAP compete.
- •Limited dexterity versus 20-DoF hands.
Wonik Robotics vs Key Competitors
Strategic capability matrix across platform categories, commercial readiness, and target markets
Category / Focus
- Allegro Hand V5
- Research hand
- Allegro Hand V5 Plus
- Research hand
- Shadow Dexterous Hand
- Research hand
- Schunk SVH
- Five-finger hand
Primary Use
- Allegro Hand V5
- Teleoperation, assembly
- Allegro Hand V5 Plus
- Teleoperation, assembly
- Shadow Dexterous Hand
- Teleoperation, assembly
- Schunk SVH
- Service robotics, AI grasping research
Degrees of Freedom
- Allegro Hand V5
- 9 (base, 3 fingers × 3 DOF); 16 (Plus, 4 fingers × 4 DOF)
- Allegro Hand V5 Plus
- 16
- Shadow Dexterous Hand
- 24 (20 actuated + 4 underactuated)
- Schunk SVH
- 20
Release Year
- Allegro Hand V5
- 2025
- Allegro Hand V5 Plus
- 2025
- Shadow Dexterous Hand
- 2004
- Schunk SVH
- 2013
| Strategic Dimension | Allegro Hand V5 | Allegro Hand V5 Plus | Shadow Dexterous Hand | Schunk SVH |
|---|---|---|---|---|
| Category / Focus | Research hand | Research hand | Research hand | Five-finger hand |
| Primary Use | Teleoperation, assembly | Teleoperation, assembly | Teleoperation, assembly | Service robotics, AI grasping research |
| Degrees of Freedom | 9 (base, 3 fingers × 3 DOF); 16 (Plus, 4 fingers × 4 DOF) | 16 | 24 (20 actuated + 4 underactuated) | 20 |
| Release Year | 2025 | 2025 | 2004 | 2013 |
Corporate Ecosystem & Ownership Structure
Parent company relationships, historical acquisitions, and global operating facilities
Global Facilities & Operating Hubs
Wonik Robotics Headquarters
HQSeongnam-Si, South Korea
Frequently Asked Questions
8 AnswersVerified answers, company specifications, and deployment details about Wonik Robotics
What is Wonik Robotics?
Wonik Robotics is a South Korean company in Seongnam, founded in 2004 as SimLab, that makes the Allegro Hand and other robotics hardware and control software.
What is the Allegro Hand?
The Allegro Hand is a multi-fingered robot hand for research, commercialised by Wonik under licence from technology of the Korea Institute of Industrial Technology.
What is the Allegro Hand V5?
The Allegro Hand V5 is a compact three-finger robotic hand with a nine degree-of-freedom structure for grasping and manipulation research, also sold as V5 Plus and V5 Sense.
How is Wonik working with Meta?
Wonik is developing a next-generation Allegro Hand with Meta's Digit Plexus tactile technology, which it will manufacture and distribute for researchers.
Who founded Wonik Robotics?
Kyong-Sok Chang founded the company in 2004 when it was known as SimLab. Wonik Robotics is a South Korean robotics company in Seongnam, founded in 2004 by Kyong-Sok Chang and formerly known as SimLab, that develops robotics hardware and software control systems.
What is the Allegro Dog?
The Allegro Dog is a quadruped robot from Wonik Robotics that the company delivered to the US Naval Research Laboratory.
Does the Allegro Hand have safety certification?
Wonik obtained CE certification for the Allegro Hand V5 and V5 Plus, according to its company history. Wonik Robotics is a South Korean robotics company in Seongnam, founded in 2004 by Kyong-Sok Chang and formerly known as SimLab, that develops robotics hardware and software control systems.
Where is Wonik Robotics based?
Wonik Robotics is based in Seongnam-si, South Korea. Wonik Robotics is a South Korean robotics company in Seongnam, founded in 2004 by Kyong-Sok Chang and formerly known as SimLab, that develops robotics hardware and software control systems.
Verified Data & Editorial Assurance
Compiled from verified corporate filings, official Wonik Robotics datasheets, and robotics engineering registries. Information has been verified against official manufacturer documentation. For commercial procurement or proprietary integrations, contact the manufacturer directly.