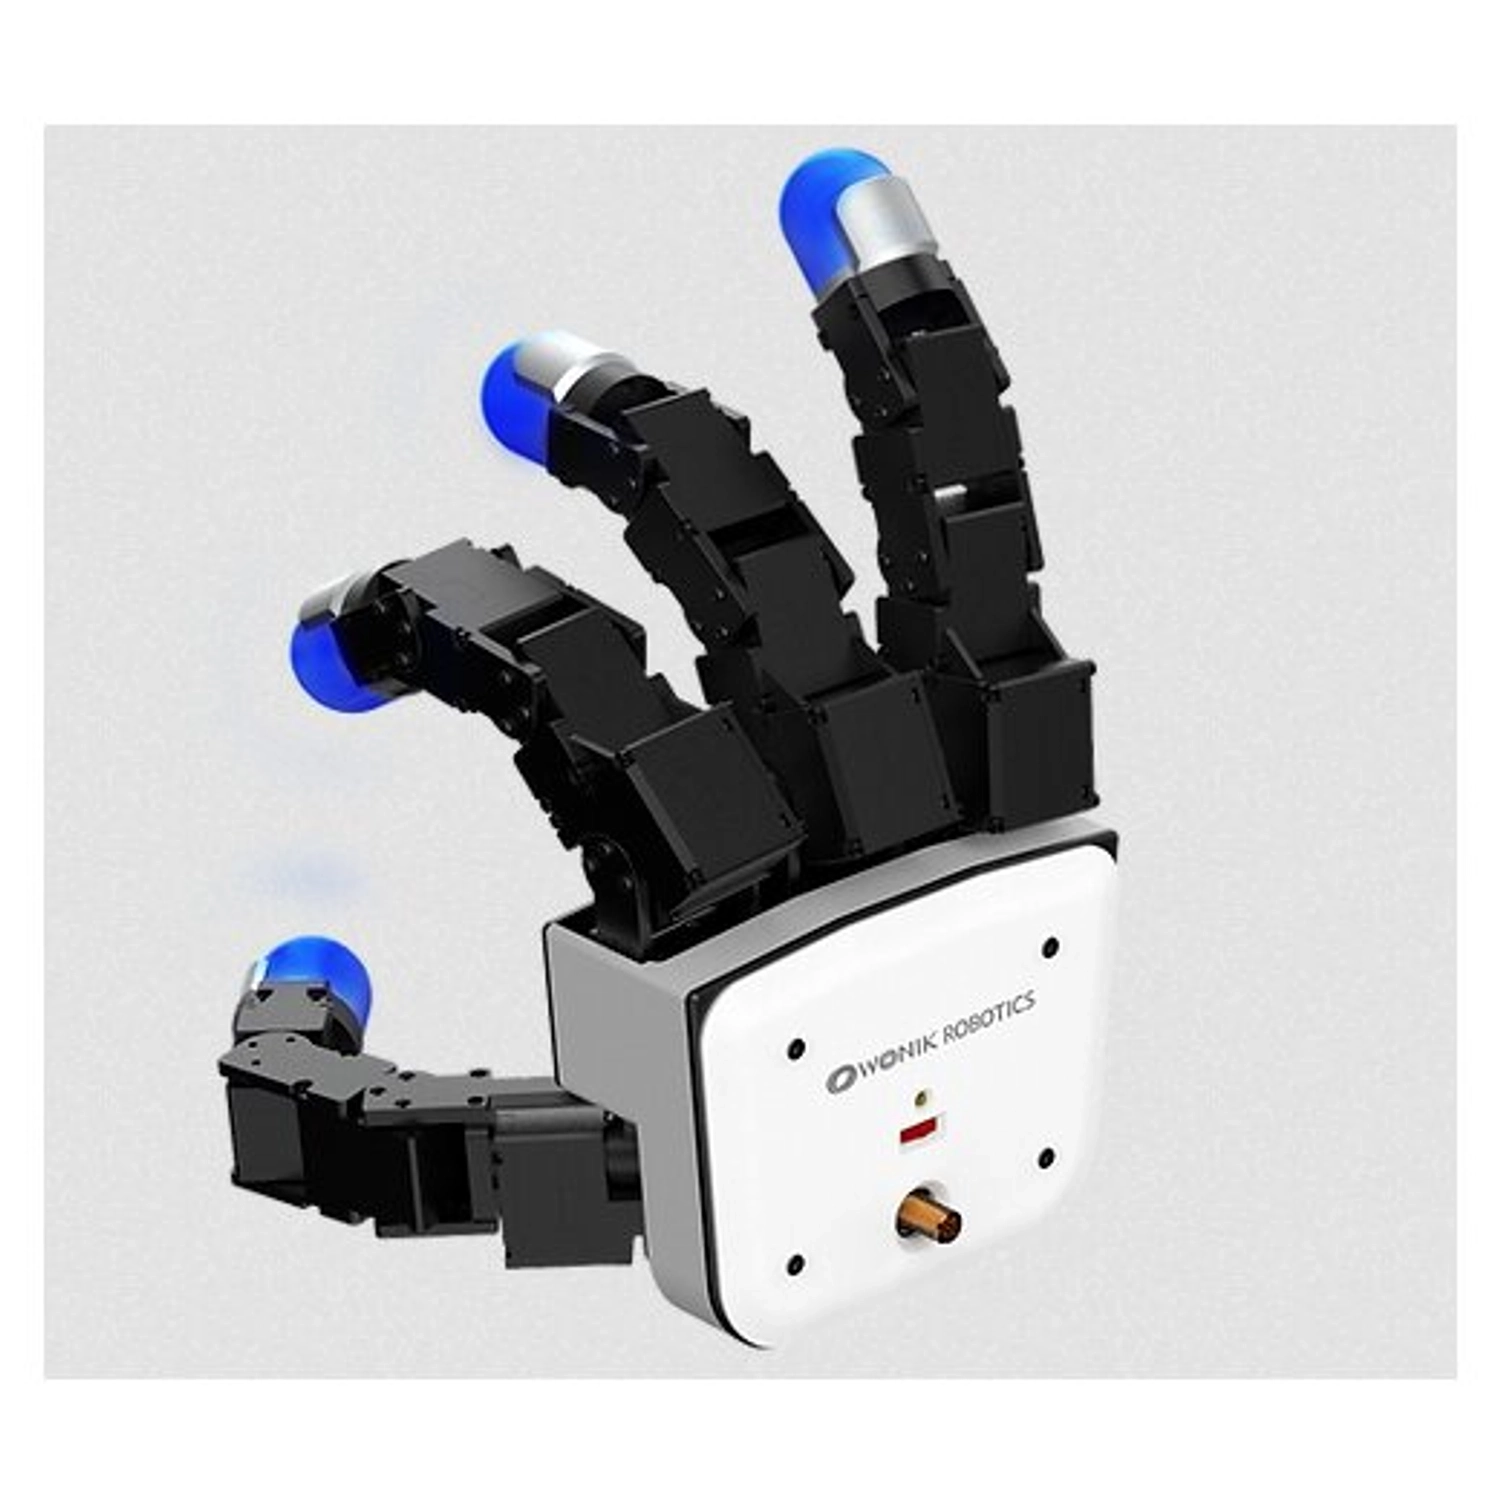
Allegro Hand V5 Plus
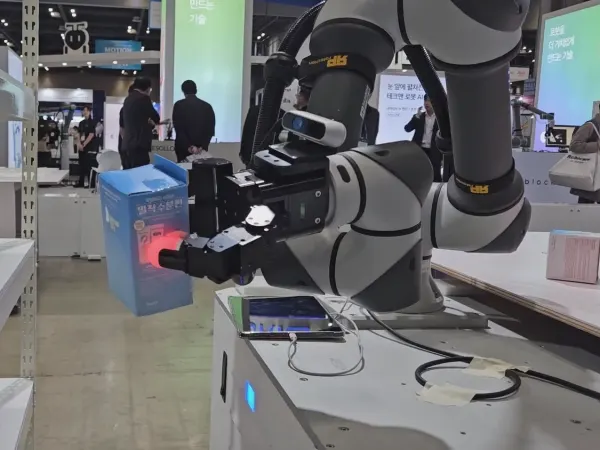
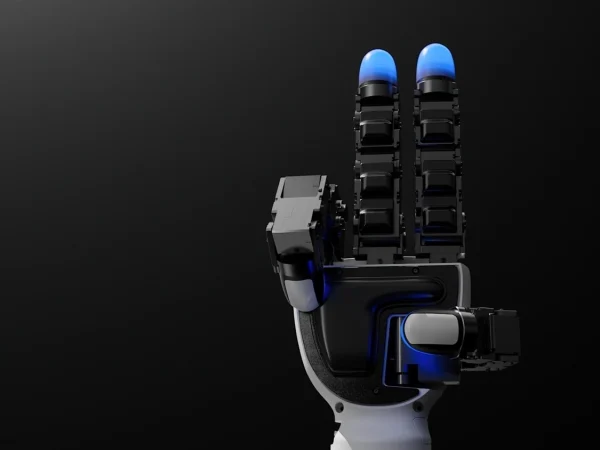
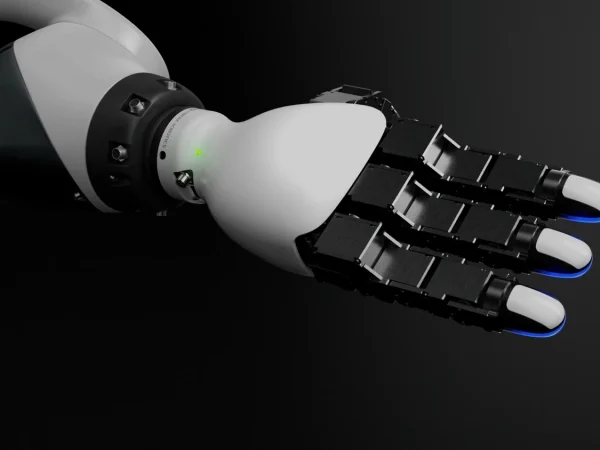
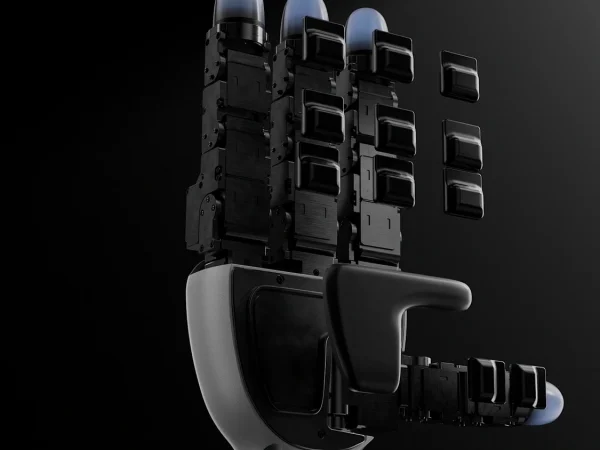
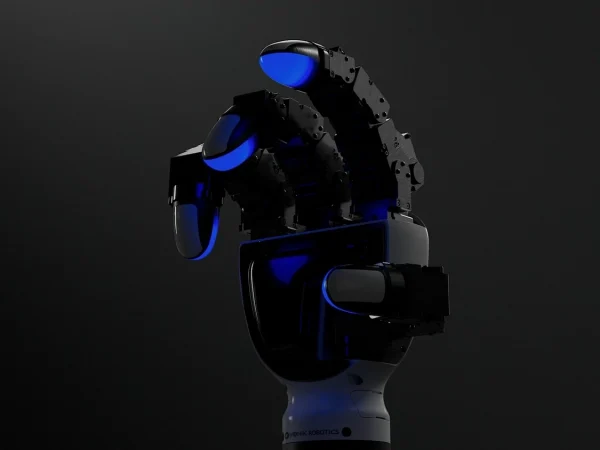
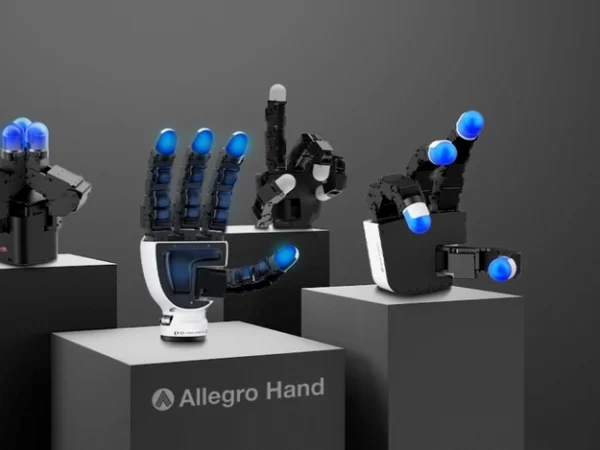
The Allegro Hand V5 Plus is a highly dexterous, 4-finger robotic hand with 16 degrees of freedom, featuring independent current/torque-controlled joints for precise grasping and manipulation of diverse objects (rigid or soft). Designed for research, it supports real-time control, online simulation, and optional 360° pneumatic tactile fingertip sensors. Enhanced components enable stable handling up to 15 kg payload, with CAN communication at 500 Hz for advanced applications in robotics R&D and automation.
Robot Specifications
Image Gallery
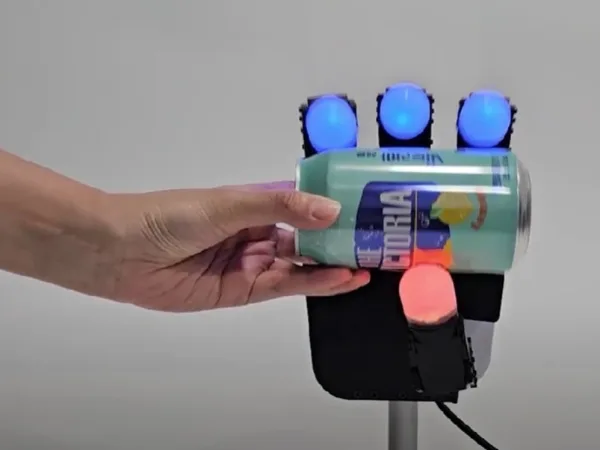
Below images are from Wonik Robotics's official sources
Review Videos
Watch expert reviews and demonstrations of this robot
More Robots from Wonik Robotics
Explore other robots from this manufacturer
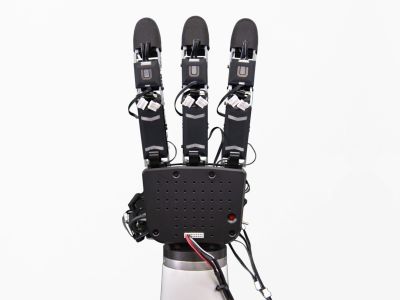
Allegro Hand V4
By: Wonik Robotics
Launched: 2024
The Allegro Hand V4 is a lightweight, dexterous robotic hand with 4 fingers and 16 independent torque-controlled joints, designed for advanced grasping, manipulation research, and robotics development. It supports real-time control via CAN at high frequency, enabling complex motions, learning-based control, and human-inspired grasping. Compact and adaptable for desktop or arm-mounted use, it facilitates studies in embodied AI, teleoperation, and dexterous manipulation without hardware setup burdens.
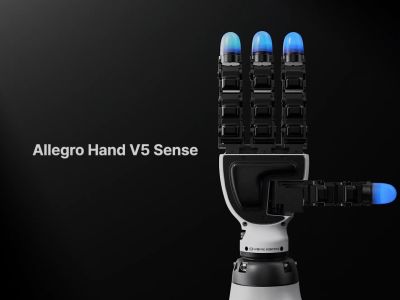
Allegro Hand V5 Sense
By: Wonik Robotics
Launched: 2025
The Allegro Hand V5 Sense is an advanced dexterous robotic hand by Wonik Robotics featuring 16 pressure sensors for precise tactile feedback and natural grasping capabilities. Equipped with adduction and abduction movements, it supports both CAN bus and Ethernet communication for reliable real-time control. Designed for research, education, and industrial applications requiring high-precision manipulation and haptic awareness.
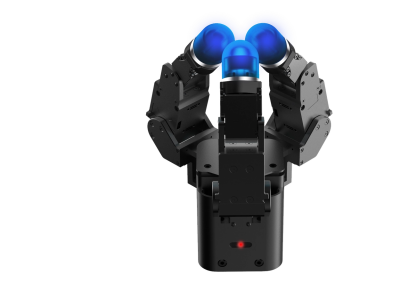
Allegro Hand V5
By: Wonik Robotics
Launched: 2025
The Allegro Hand V5 is a compact, torque-controlled robotic hand with 3-4 anthropomorphic fingers, designed for precise, compliant manipulation in research, education, and industrial applications. It features DC motor actuation, high-resolution joints, optional tactile sensors, and real-time CAN control at 500 Hz, supporting dexterous grasping of varied objects with payloads up to 12 kg depending on configuration and grasp type.
Frequently Asked Questions
Get answers to common questions about this robot
Q1.What are the degrees of freedom (DOF) and finger configuration of the Allegro Hand V5 Plus?
The Allegro Hand V5 Plus features **4 fingers** (3 fingers + 1 thumb) with a total of **16 active DOF** (4 DOF per finger), enabling precise and human-like dexterous grasping and manipulation.
Q2.What is the grip strength and payload capacity of the Allegro Hand V5 Plus?
It offers a **stall torque of 0.92 N·m (typical) to 1.84 N·m** (2nd joint of fingers, excluding thumb), **nominal torque of 0.23 N·m to 0.46 N·m**, and can handle a **payload up to 15 kg** (depending on measurement method), suitable for grasping rigid or soft objects of various shapes.
Q3.What are the power requirements and weight of the Allegro Hand V5 Plus?
The hand requires **24 V / 5 A / 120 W** power (compatible with 12-24 V systems) and weighs approximately **1.02-1.20 kg** (manufacturer vs. shop listing, may include cabling variance).
Q4.What programming and SDK options are available for the Allegro Hand V5 Plus?
It includes the **Allegro Hand Console Application** for simulation-based algorithm prototyping, hardware testing, and ready-to-use grasping algorithms; supports real-time control, custom CAN interfaces (e.g., NI/Peak), and OS like Windows (XP/7/8, Visual Studio) and Linux (ROS).
Q5.What are the main use cases for the Allegro Hand V5 Plus?
Designed for **dexterous grasping, manipulation research, haptics, education, and industrial applications** like handling diverse object geometries (rigid/soft), contact-rich tasks, and simulation-based experimentation.
Q6.What safety features does the Allegro Hand V5 Plus have for operation?
Features **current-controlled joints** with high joint resolution (0.088°), torque control for precise movements, and gear ratios (288.35
Q7.What is the pricing for the Allegro Hand V5 Plus?
Pricing is not listed in available specifications; contact suppliers like MYBOTSHOP GmbH or Wonik Robotics directly for quotes on configurations (with/without fingertip sensors), as it varies by revision, SKU, and package contents.
Q8.How does the Allegro Hand V5 Plus integrate with full humanoid robots or arms?
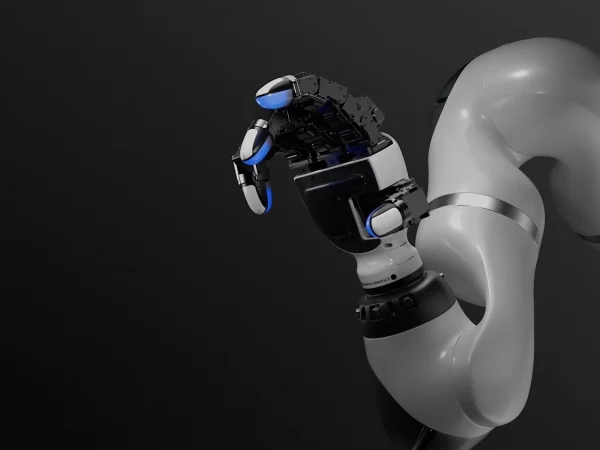
Its **compact 1.20 kg design**, CAN interface, and ROS compatibility make it ideal for mounting on humanoid arms; supports custom tooling like GUI control and fingertip upgrades for contact-rich tasks in research setups.
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments are reviewed before posting.