China Subsidizes Robot Failures: National Innovation Centers Bank 24,000 Daily Datasets to Conquer Embodied Physical AI
Robot Details
Robotics & AI News • OriginOfBotsPublished
September 20, 2026
Reading Time
5 min read
Author
Origin Of Bots Editorial Team
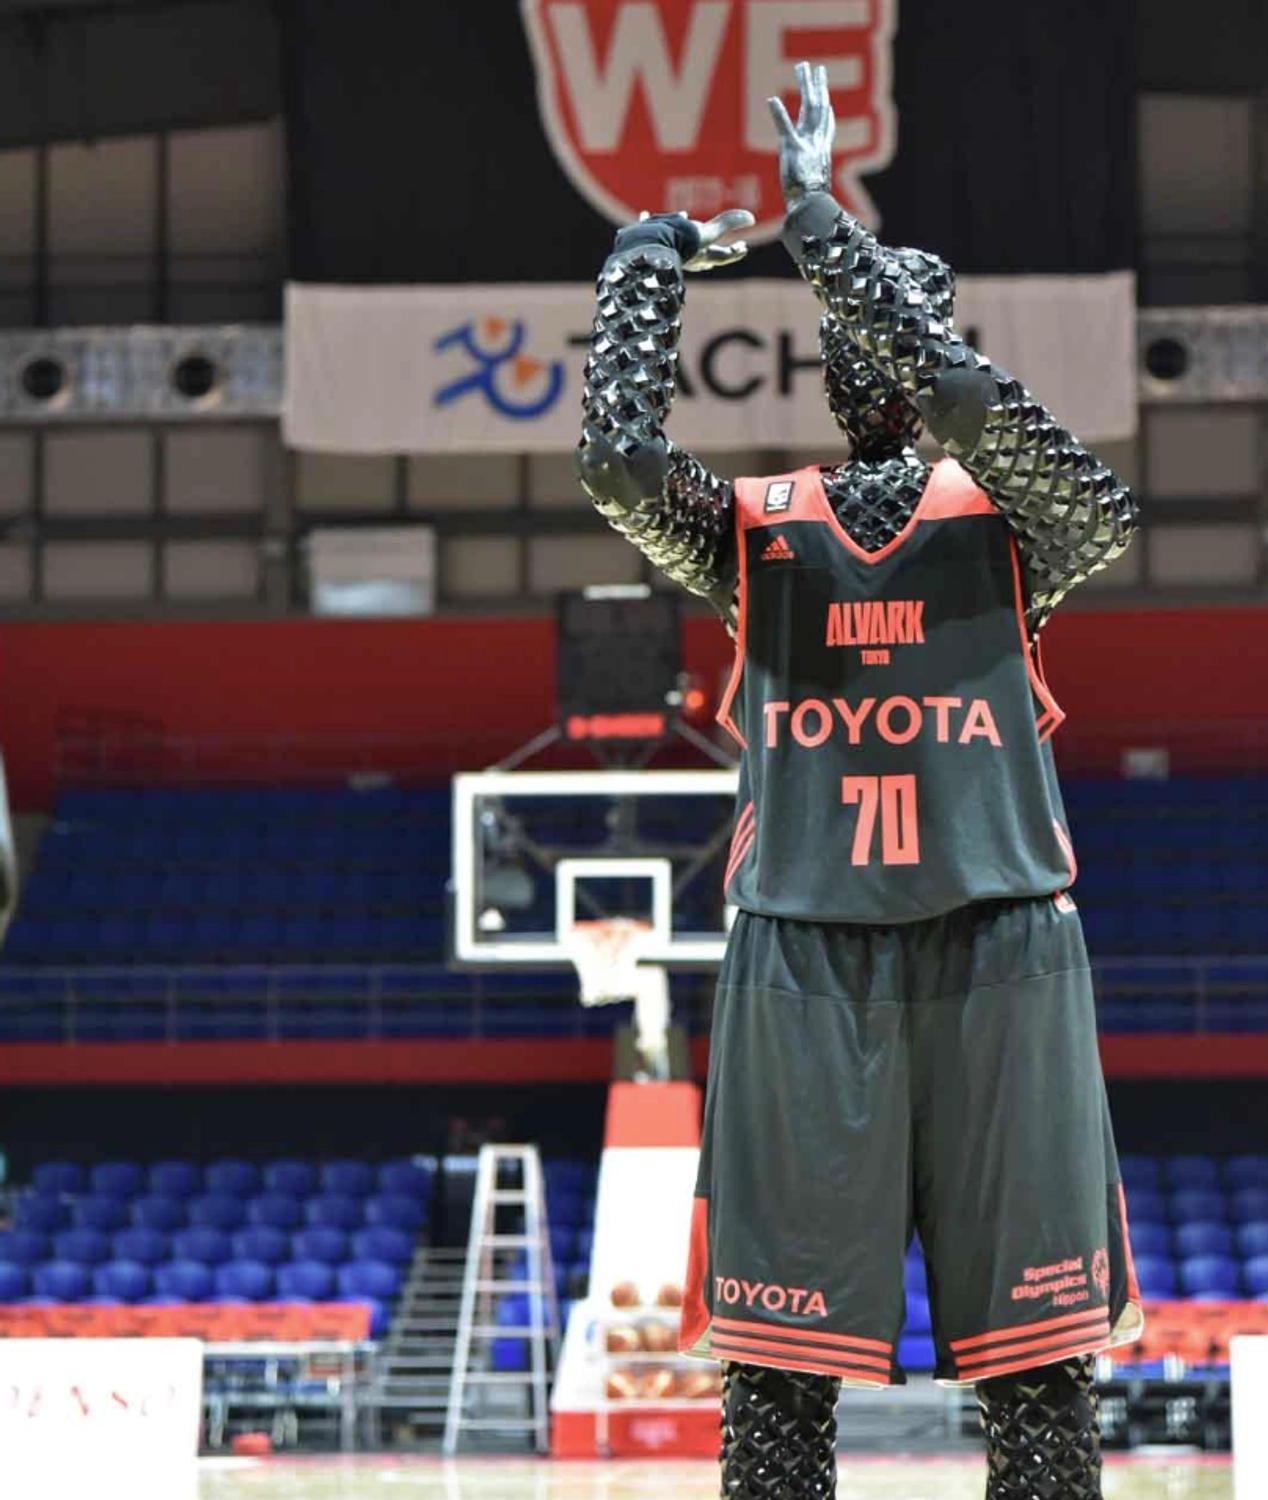
Inside Wuhan's Proving Ground: Subsidizing the Science of Failure
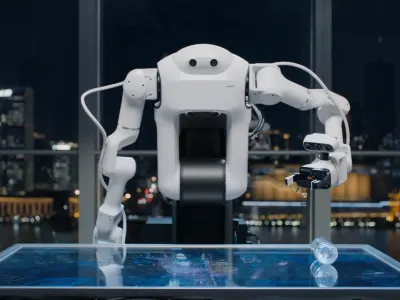
At the Hubei Humanoid Robot Center in Wuhan’s Optics Valley, an unusual industrial scene unfolds across sprawling obstacle courses. Dozens of experimental humanoid robots continuously stumble over uneven floors, drop fragile glassware, and spill cups of tea onto testing tables. Far from viewing these blunders as costly embarrassments, Chinese municipal authorities are actively subsidizing every recorded mistake with public funds.
The Wuhan innovation hub generates approximately 24,000 unique data entries every single day, converting mechanical mishaps into high-value training assets. Municipal officials recognize that achieving genuine machine intelligence requires exposing artificial neural networks to the full spectrum of physical failure modes. By underwriting this deliberate trial-and-error curriculum, regional planners are constructing an unprecedented empirical moat in embodied artificial intelligence.
The National Network: Rapid Proliferation of 110 Robotic Data Centers
The Wuhan testing complex is merely one node in an expansive, state-orchestrated network spanning mainland China’s industrial corridors. Following national development guidelines issued by the Ministry of Industry and Information Technology, China established 22 provincial-level innovation centers in just fourteen months. Complementing these flagship facilities are more than ninety municipal data collection hubs currently operating, under construction, or in late planning stages.
This rapid national rollout occurred at a velocity that far surpassed earlier state initiatives in electric vehicles and semiconductor manufacturing. Government directives mandate that humanoid robots achieve validated deployment capabilities across ten thousand distinct operating sites before the close of the year. Public events such as robotic obstacle courses and marathon challenges are systematically utilized to capture high-stress kinetic telemetry under variable conditions.
The Data Imperative: Why Embodied Intelligence Cannot Rely on Internet Scrapes
The underlying motivation behind China’s aggressive data stockpiling stems from a profound technical bottleneck in physical artificial intelligence. Unlike generative conversational models that train effortlessly on trillions of text tokens scraped from the public internet, physical robots require grounded kinetic telemetry. Neural networks operating in the material world must understand joint torque resistance, tactile friction gradients, and gravitational inertia.
Because high-fidelity physical interaction data cannot be synthesized purely through virtual software simulations, real-world data collection has become the primary global bottleneck. Industry analysts from Samsung Securities recently evaluated Chinese robotics hubs, concluding that the defining competitive constraint no longer involves mechanical hardware, but the robot's brain. Accumulating millions of empirical physical interaction tokens is universally acknowledged as the prerequisite for triggering a ChatGPT-style breakthrough in robotics.
The Value of Negative Data in Vision-Language-Action Models
Leading academic researchers point out that conventional robotics training corpora suffer from a severe structural imbalance: an overabundance of pristine success demonstrations. Chen Tao, head of Fudan University’s deep learning research institute, emphasized that contemporary Vision-Language-Action models cannot achieve true autonomy without extensive failure data. Robots trained exclusively on flawless executions experience catastrophic policy collapse when confronted with minor real-world slips or misplaced parts.
Exposing neural policies to thousands of dropped objects and unstable footing forces the AI to learn autonomous error-correction and dynamic recovery trajectories. When a robot spills tea in Wuhan, onboard sensors log the precise fingertip pressure slip and center-of-mass shift that precipitated the accident. Converting these physical failures into structured training weights enables neural models to self-correct in real time when unexpected workplace disruptions occur.
Dominating the Global Data Commons: 90% Market Share at 60% Lower Cost
China's aggressive state-backed data accumulation strategy has already yielded a commanding quantitative advantage over international competitors. Evaluations by prominent artificial intelligence infrastructure firm Scale AI reveal that China currently controls approximately ninety percent of commercially available robot training data. Furthermore, leveraging vast domestic labor forces to annotate and supervise testing operations enables Chinese hubs to produce data at sixty percent lower cost than American rivals.
Guo Ping, chairman of Huawei's supervisory board, recently analyzed the global artificial intelligence competition across computing power, algorithmic talent, and empirical data. Guo observed that while China continues to face geopolitical headwinds in advanced semiconductor computing clusters, its structural dominance in physical data remains unmatched. Combining mass-produced hardware chasses with low-cost human annotators enables domestic robotics developers to scale neural model training with unmatched velocity.
Emerging Bubble Risks and the Scrutiny of Artificial Demand
Despite dramatic quantitative achievements, China’s state-subsidized data collection model is encountering mounting commercial skepticism and structural strain. Critics argue that aggressive municipal subsidies risk replicating the destructive overcapacity cycles previously witnessed in solar panels and electric vehicle batteries. In many regional partnerships, local governments provide up to ninety percent of initial capital outlays to purchase robots and finance ongoing data harvesting.
However, commercial demand from independent enterprise buyers to purchase these stockpiled datasets remains largely unproven and financially insufficient. Illustrating these operational frictions, Beijing’s Shijingshan humanoid robot training hub recently terminated its public-private partnership with robotics maker RealMan. Municipal managers cited substandard data quality and inadequate commercial revenues as primary justifications for dissolving the multimillion-yuan collaboration.
The Strategic Synthesis of Empirical Data and Global Hegemony
Notwithstanding emergent commercial growing pains, Chinese state planners view the subsidization of robotic failure as an acceptable strategic trade-off. By accepting near-term capital inefficiencies, Beijing aims to secure insurmountable data assets before international rivals can establish comparable collection networks. The ultimate objective is to cultivate native foundation models that possess an intuitive, physics-grounded understanding of human environments and industrial labor.
As thousands of imperfect bipedal machines continue to tumble, recover, and log telemetry across Chinese proving grounds, their collective intelligence compounds daily. Whether this aggressive accumulation strategy sparks the long-anticipated breakthrough in generalized physical robotics will define the next decade of technology competition. China's bold willingness to fund mistakes today may well provide the empirical foundation that powers the autonomous industrial workforces of tomorrow.
Related Articles
International Broadcasters Spotlight Viral Milestone of Humanoid Robot Autonomously Walking Off Assembly Line
Samsung Begins Prototype 2nm AI5 Chip Fabrication for Tesla FSD and Optimus Humanoid Robots
ETH Zurich Unveils 'Fingers as Legs': Anthropomorphic Hands Master Untethered Locomotion and Mobile Manipulation
Spirit AI Forecasts General-Purpose Humanoid Robot Brains Poised for a 'ChatGPT-Style' Inflection by 2027
Learn More About This Robot
Discover detailed specifications, reviews, and comparisons for Robotics & AI News.
View Robot Details →