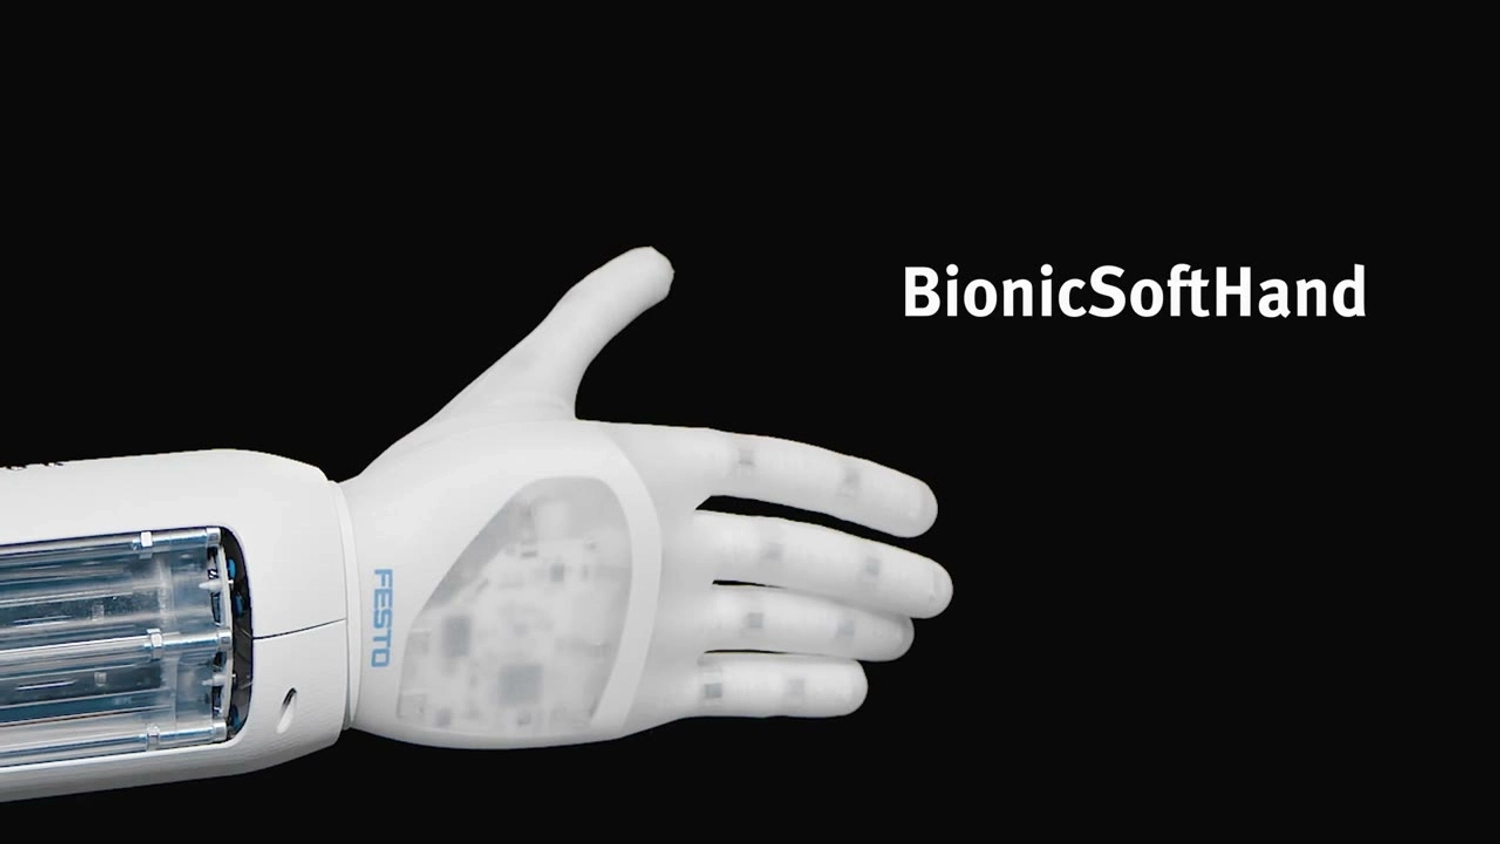
BionicSoftHand
AI ChatLast updated:
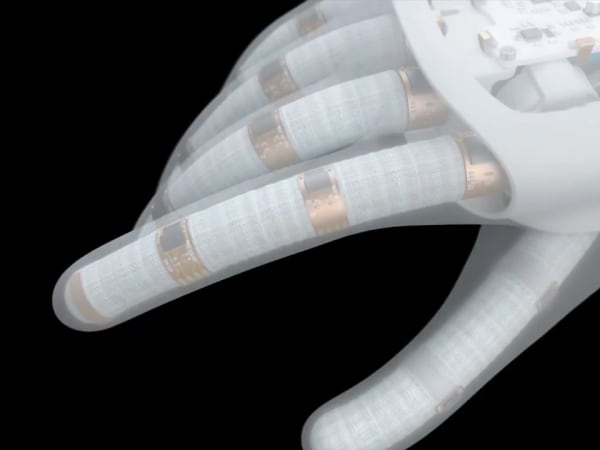
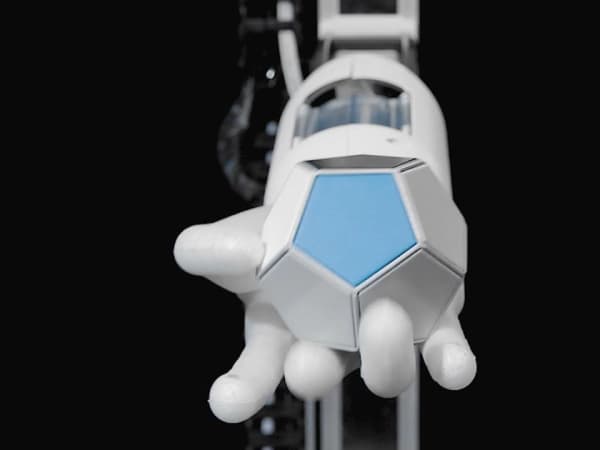
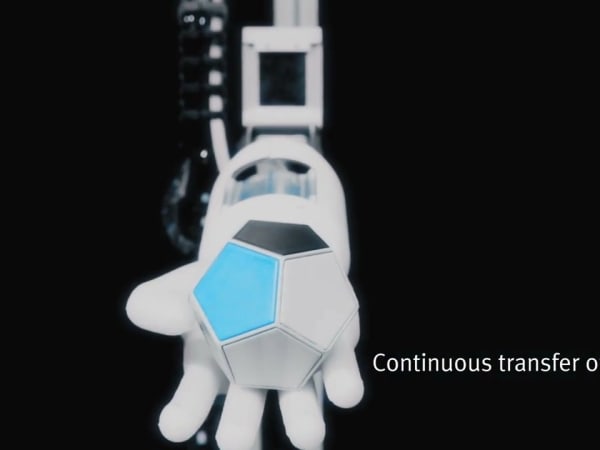
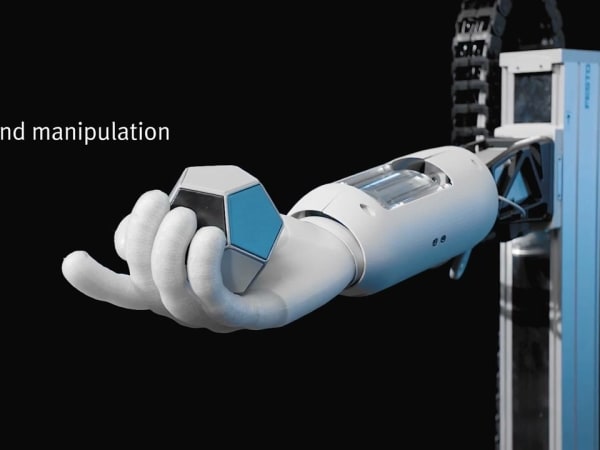
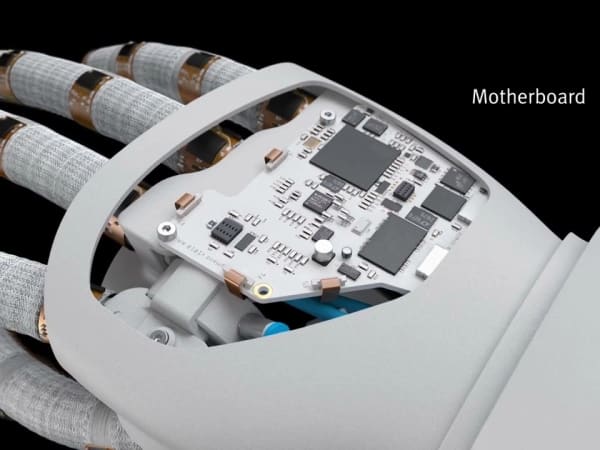
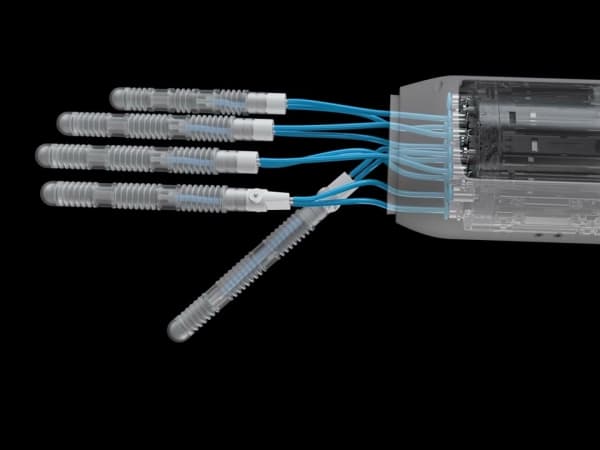
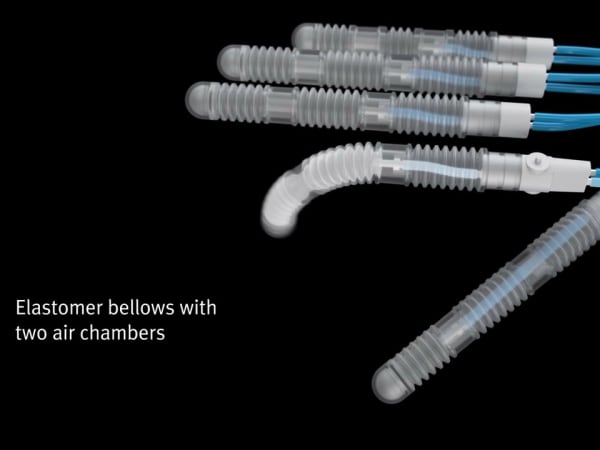
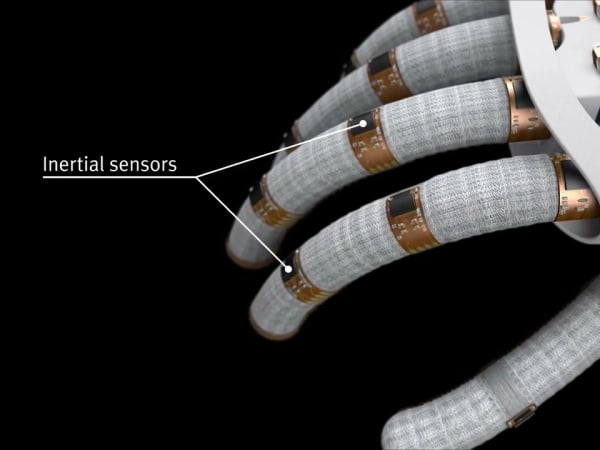
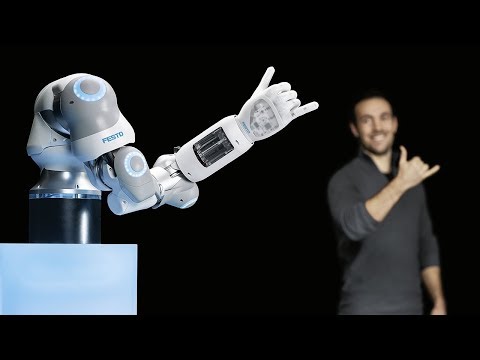
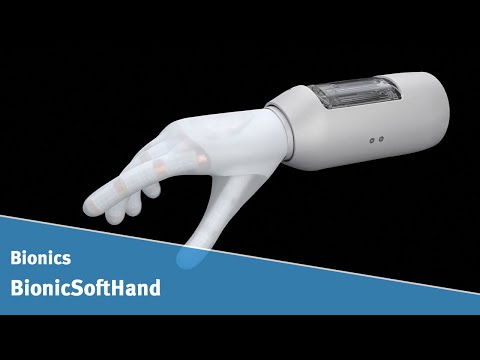
BionicSoftHand is Festo's pneumatic soft robot hand, shown at Hannover Messe 2019 and modelled on the human hand. It has no rigid bones: each finger is an elastomer bellows with air chambers inside a knitted textile coat, bent by compressed air that is metered by proportional piezo valves. A flexible circuit board in the fingers carries inertial and tactile force sensors. Festo trains it with reinforcement learning on a digital twin, so it can learn tasks such as turning a twelve-sided cube in the palm. It is a research platform and later joined Festo's BionicMobileAssistant system.
Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by Festo: warranty terms, safety certifications, EMC compliance, IP rating, noise level, expected lifespan, maintenance schedule, firmware version and 7 more.
Image Gallery
Below images are from Festo's official sources
Review Videos
Watch expert reviews and demonstrations of this robot
BionicSoftHand vs AIDIN Hand Gen1, LEAP Hand V2 and ORCA Hand
BionicSoftHand trails the closest alternatives on degrees of freedom and max payload, so it is better judged by how well it fits research.
Green marks the best figure in a row (highest degrees of freedom and max payload). Ranges are not ranked.
| Spec | BionicSoftHandFesto | AIDIN Hand Gen1AIDIN Robotics | LEAP Hand V2Carnegie Mellon University | ORCA HandETH Zurich (Robotic Systems Lab) |
|---|---|---|---|---|
| Degrees of Freedom | 12 | 15 | 22 | 17 |
| Max Payload | 4 kg | 15 kg | 5 kg | 1.5 kg |
| Hand Type | soft robotic | anthropomorphic | anthropomorphic | anthropomorphic |
| Fingers | 5 | 5 | 5 | 5 |
| Best For | Research | Research | Teleoperation | Teleoperation |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all humanoid robot hands
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is the humanoid robot hand BionicSoftHand, and what problem does it solve?
BionicSoftHand is a soft pneumatic robot hand from Festo. It explores how safe, compliant hands that learn can handle the varied objects found in human workplaces.
Q2. What are the main capabilities and key features of BionicSoftHand?
Its key features are bone-free air-driven fingers, a knitted textile coat, fine proportional valve control, built-in sensors and training by reinforcement learning on a digital twin.
Q3. Which industries and use cases is BionicSoftHand built for?
It is aimed at automation research, human-robot collaboration, assembly assistance and logistics.
Q4. What is the grip strength and dexterity of BionicSoftHand?
It combines strong, compliant grasping with fine finger control and can learn to rotate objects inside the hand.
Q5. Is BionicSoftHand compatible with standard robotic arms?
It was built to sit on Festo's own robot arms, so it is not a drop-in hand for arbitrary arms.
Q6. Does BionicSoftHand support tactile sensing or force feedback?
Yes. Tactile force and inertial sensors in the fingers give the controller feedback on contact and finger pose.
Q7. What programming interfaces or SDKs are available for BionicSoftHand?
It is a research system; control is driven by learned policies, and Festo does not publish a general SDK.
Q8. How does BionicSoftHand compare to other robotic end-effectors?
Compared with rigid, motor-driven hands it is lighter, softer and safer around people, but less precise and dependent on compressed air.
Q9. What level of maintenance is required for BionicSoftHand?
The soft bellows and valves need routine checks as with other pneumatic systems, and Festo handles servicing of the research unit.
Q10. Is BionicSoftHand currently available for commercial purchase?
No. It is a Festo research platform and is not sold as a standard product.
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.