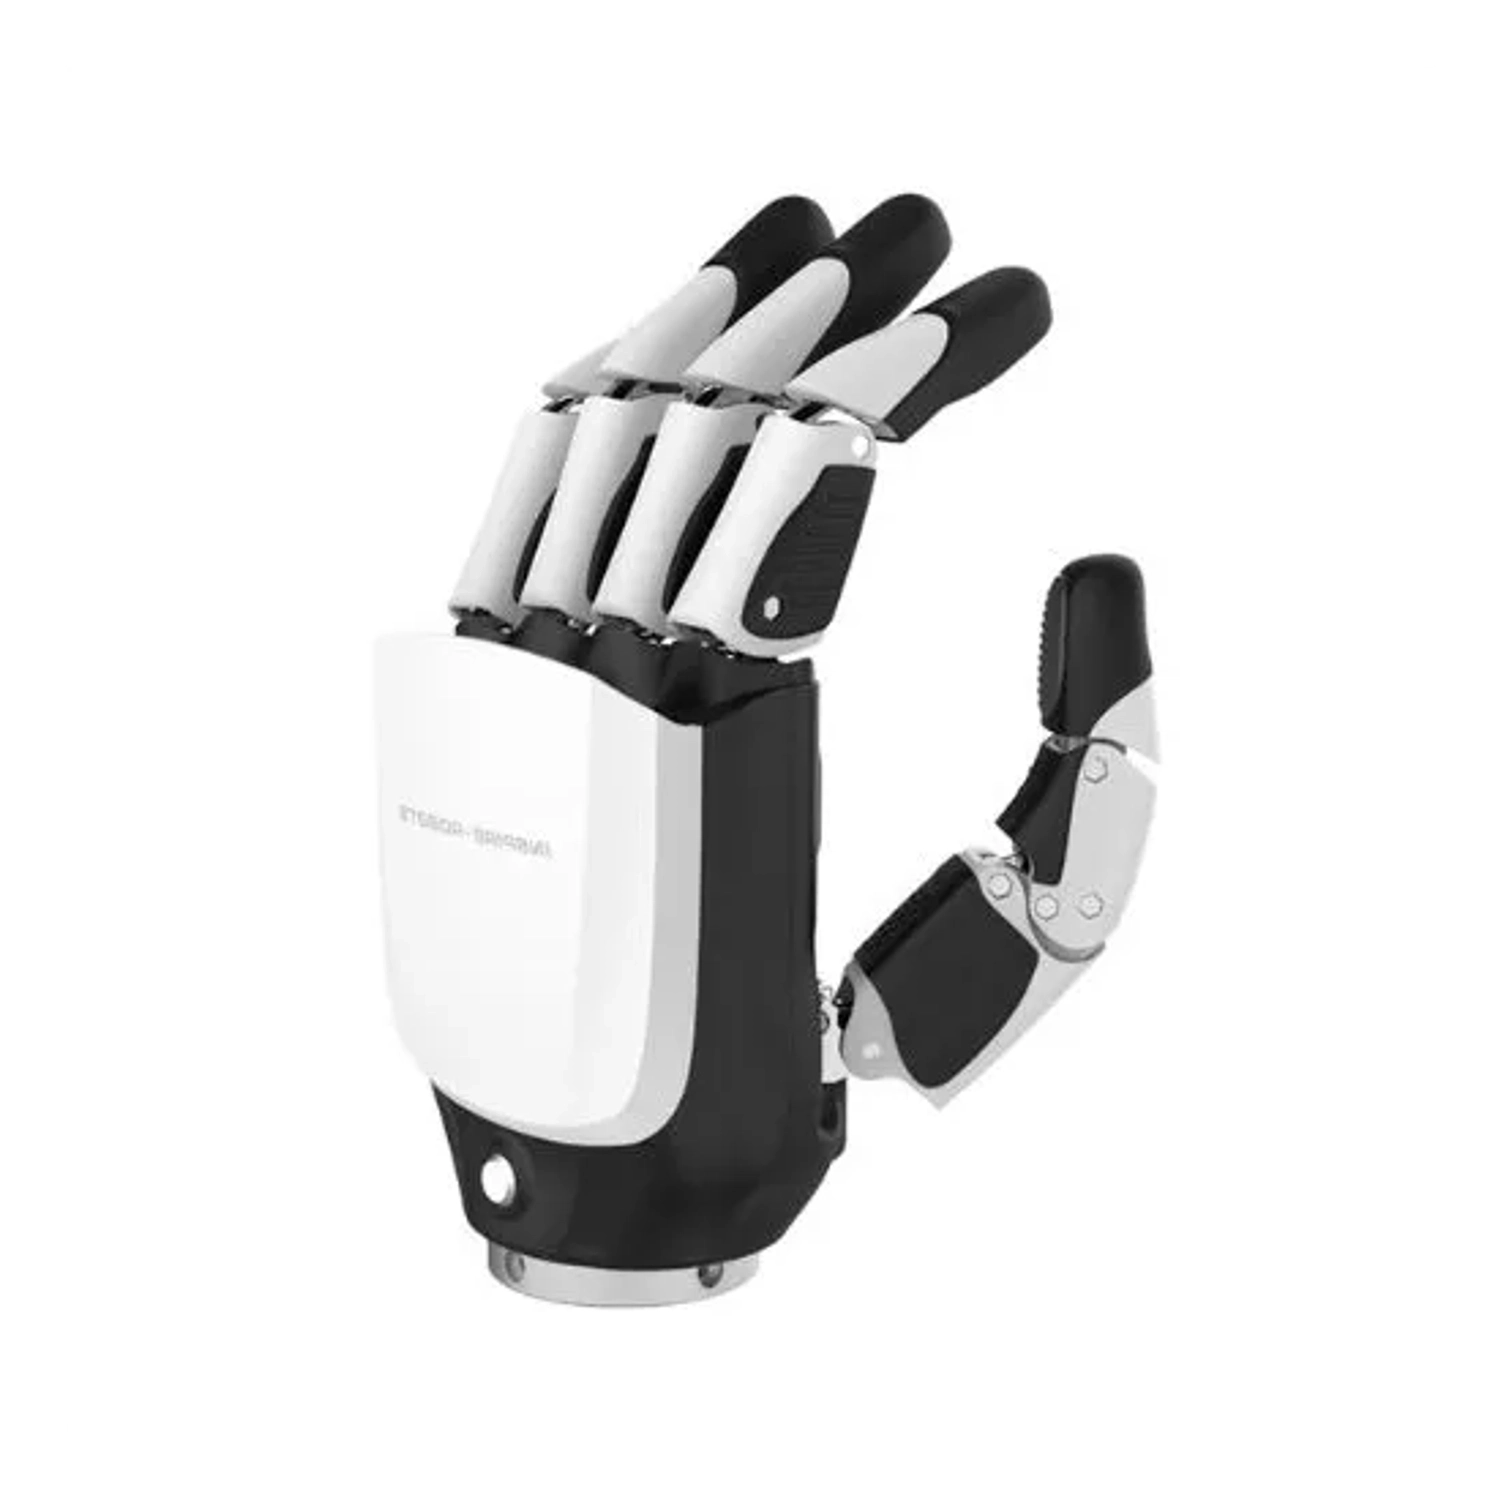
RH56E2
AI ChatLast updated:
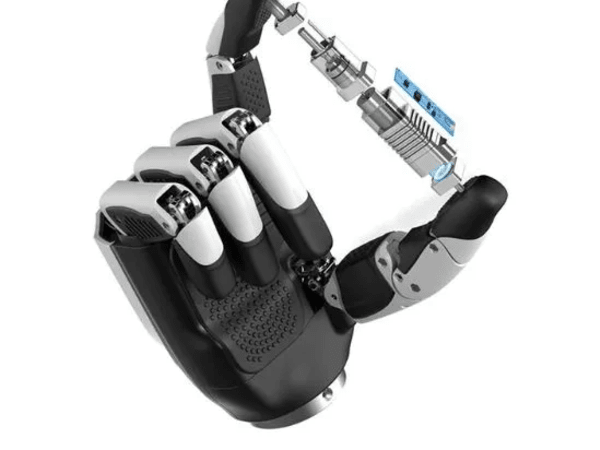
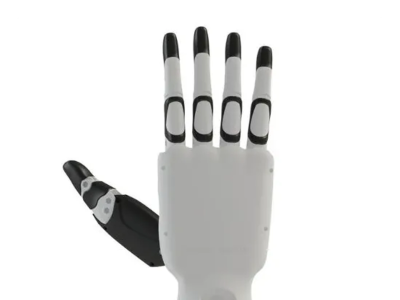
The RH56E2 Series is a five-finger dexterous robotic hand featuring 6 degrees of freedom with integrated tactile sensing capabilities. Designed for humanoid and service robotics applications, it combines reliable grip strength (up to 15 kg) with real-time tactile feedback from 17 sensors distributed across the hand, enabling precise object manipulation and adaptive force control for both delicate and demanding tasks.
Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by Inspire Robotics: EMC compliance, noise level, expected lifespan, maintenance schedule, firmware version, update method, hardware ports, color options and 4 more.
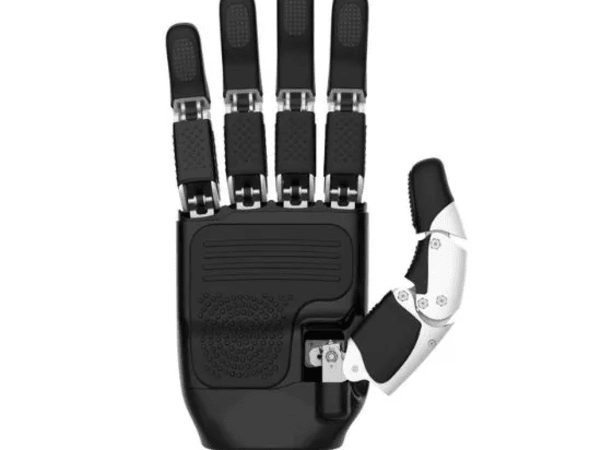
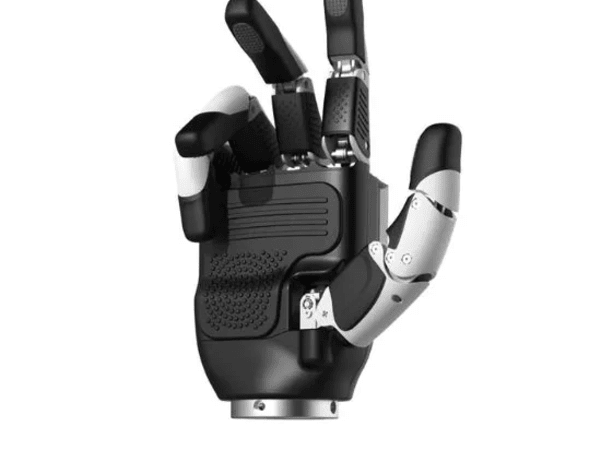
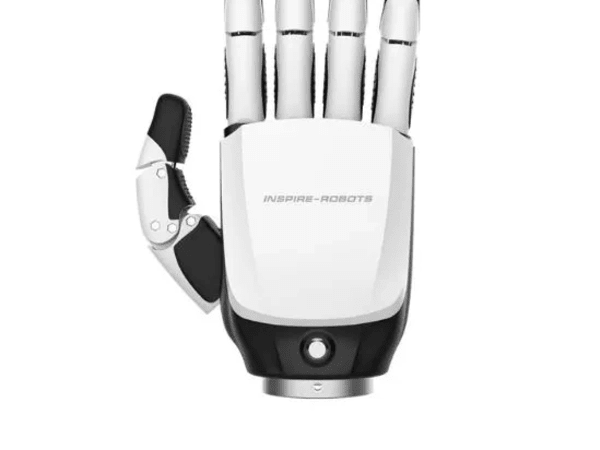
Image Gallery
Below images are from Inspire Robotics's official sources
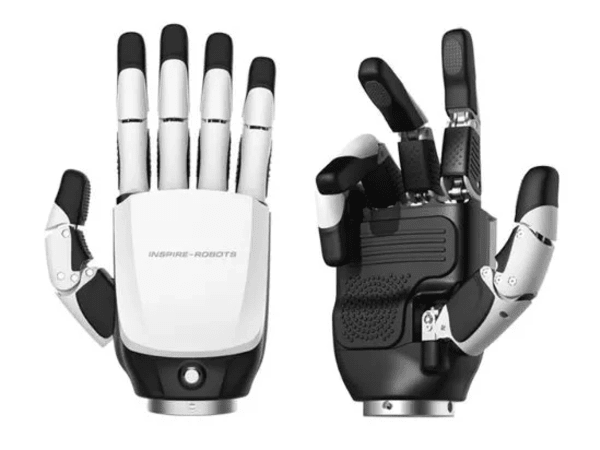
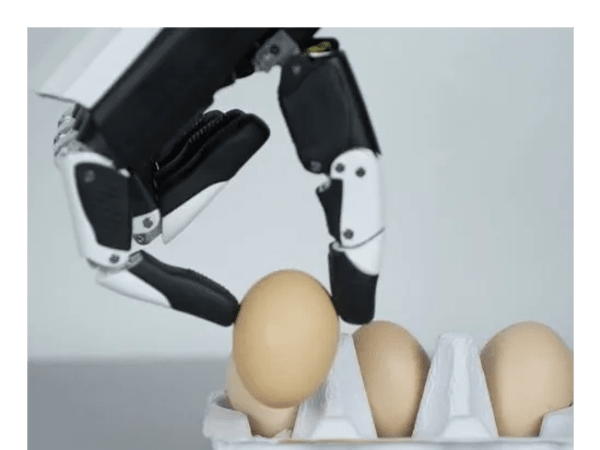
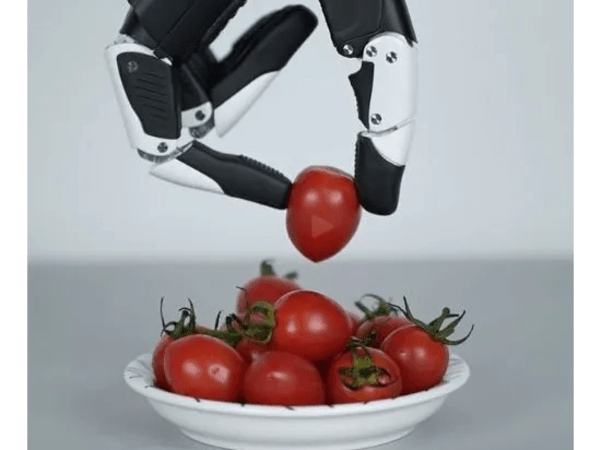
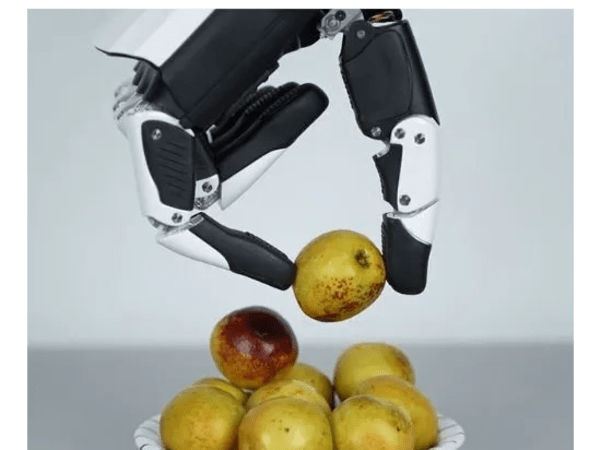
Review Videos
Watch expert reviews and demonstrations of this robot
RH56E2 vs Revo 3 Dexterous Hand, Shuqiao X2 Adaptive Hand and Clone Hand
RH56E2 leads this group on power grip force but trails on degrees of freedom, weight, max payload and closing time.
Green marks the best figure in a row (highest degrees of freedom, max payload and power grip force; lowest weight and closing time). Ranges are not ranked.
| Spec | RH56E2Inspire Robotics | Revo 3 Dexterous HandBrainCo | Shuqiao X2 Adaptive HandChangingTek Robotics | Clone HandClone Robotics |
|---|---|---|---|---|
| Degrees of Freedom | 6 | 21 | 16 | 27 |
| Weight | 850 g | 430 g | 1.2 kg | 750 g |
| Max Payload | 15 kg | 20 kg | 5 kg | 7 kg |
| Power Grip Force | 147 N | 100 N | 50 N | 66 N |
| Closing Time | 800 ms | 330 ms | — | 100 ms |
| Hand Type | anthropomorphic | anthropomorphic | anthropomorphic | anthropomorphic |
| Fingers | 5 | 5 | 5 | 5 |
| Best For | Pick-and-place tasks | Humanoid manipulation | Insertion | Teleoperation |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all humanoid robot hands
More Robots from Inspire Robotics
Explore other robots from this manufacturer
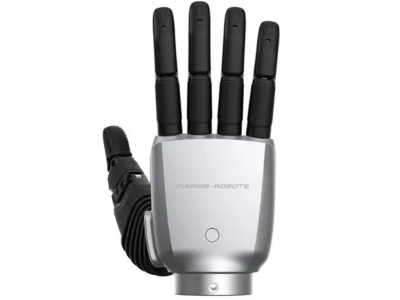
RH56F1
By: Inspire Robotics
Launched: 2023
The RH56F1 is a 5-finger dexterous robotic hand from Inspire Robotics featuring an all-metal integrated skeleton for high rigidity, 6 degrees of freedom across 12 joints, and 6 linear servo actuators for precise, human-like movements. It integrates pressure sensors for adaptive gripping of objects with varying hardness, supports force/position control, and is designed for applications like service robots, teaching aids, and prosthetics with concise interface commands for quick manipulation.
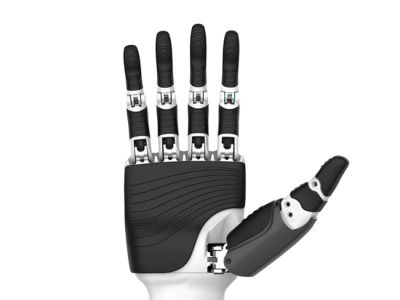
RH56DFX
By: Inspire Robotics
Launched: 2022
The RH56DFX is a dexterous humanoid robot hand from Inspire Robotics featuring an innovative linear drive design with six miniature linear servo actuators and six integrated pressure sensors. It offers 6 degrees of freedom and 12 motor joints to mimic human hand motions, enabling accurate grasping via hybrid force-position control. With moderate speed and large grip force, it supports ROS integration and is ideal for robotic grasping operations in humanoids and prosthetics.
The Pianists (RH56BFX)
By: Inspire Robotics
Launched: 2020
The RH56BFX, marketed as "The Pianists," is a high-speed dexterous robotic hand featuring six degrees of freedom and twelve motor joints. It employs an innovative linear servo actuator design with integrated force sensing for contact-aware grasping. Optimized for rapid, precise movements, it excels in applications requiring fine manipulation such as piano playing, gesture recognition, and human-robot interaction tasks.
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is the humanoid robot hand RH56E2, and what problem does it solve?
The RH56E2 is a five-finger dexterous robotic hand developed by Beijing Inspire Robots Technology Co., Ltd. (Inspire Robotics). According to the manufacturer, it addresses challenges in precise gripping and manipulation by integrating tactile sensors for real-time feedback.
Q2. What are the main capabilities and key features of RH56E2?
The RH56E2 features 6 degrees of freedom across 12 joints, up to 17 tactile sensors, and force sensing. According to the manufacturer, it provides precise control for grasping tasks with power-off self-locking capability.
Q3. Which industries and use cases is RH56E2 built for?
The RH56E2 is designed for humanoid robots, service robots, research, light industrial automation, and pick-and-place tasks. According to the manufacturer, it supports applications requiring dexterous manipulation.
Q4. What is the grip strength and dexterity of RH56E2?
The RH56E2 offers 6 degrees of freedom and five-finger dexterity. According to the manufacturer, it achieves 3 kg primary force per finger with force sensors for controlled gripping.
Q5. Is RH56E2 compatible with standard robotic arms?
Yes, the RH56E2 supports integration with common robotic arms via modular design. According to the manufacturer, it uses CAN, RS485, or ModbusTCP interfaces for compatibility.
Q6. Does RH56E2 support tactile sensing or force feedback?
The RH56E2 integrates up to 17 tactile sensors and 6 force sensors per hand. According to the manufacturer, these enable real-time tactile feedback and precise force control during operations.
Q7. What programming interfaces or SDKs are available for RH56E2?
The RH56E2 uses CAN, RS485, ModbusTCP, and Ethernet interfaces with register-based control commands. According to the manufacturer, these allow straightforward programming without specified SDK details.
Q8. How does RH56E2 compare to other robotic end-effectors?
The RH56E2 provides anthropomorphic five-finger design with integrated tactile and force sensing, differing from simpler grippers. According to the manufacturer, its 6-DoF structure suits nuanced manipulation over basic end-effectors.
Q9. What level of maintenance is required for RH56E2?
The RH56E2 features power-off self-locking and no homing requirement after power-on. According to the manufacturer, this design reduces maintenance needs for reliable operation.
Q10. Is RH56E2 currently available for commercial purchase?
The RH56E2 is listed for sale through distributors, with some variants on backorder. According to the manufacturer, it is available for research and automation applications.
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.