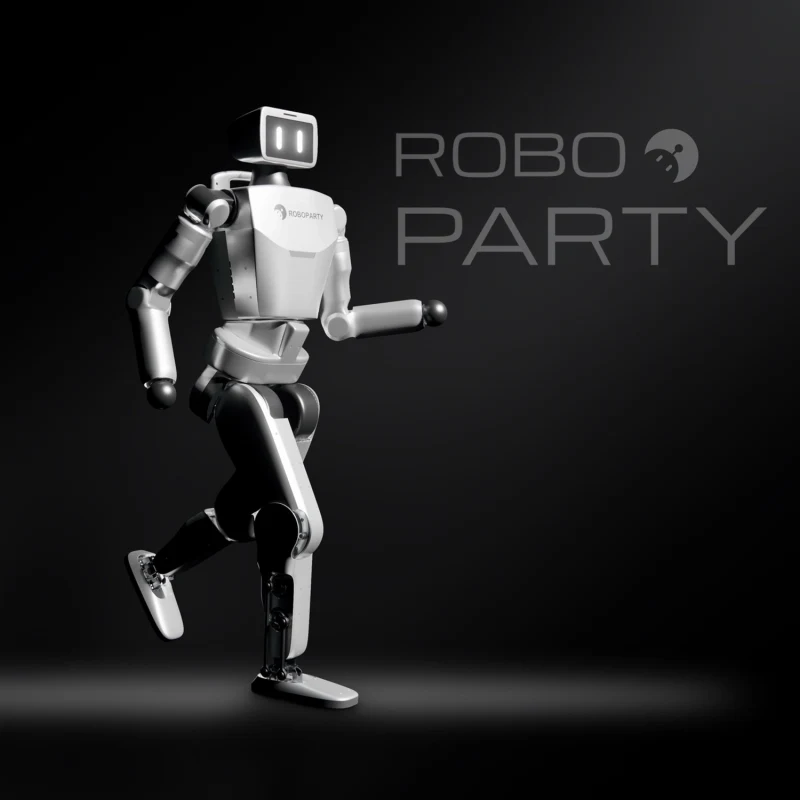
ROBOTO ORIGIN
AI ChatLast updated:
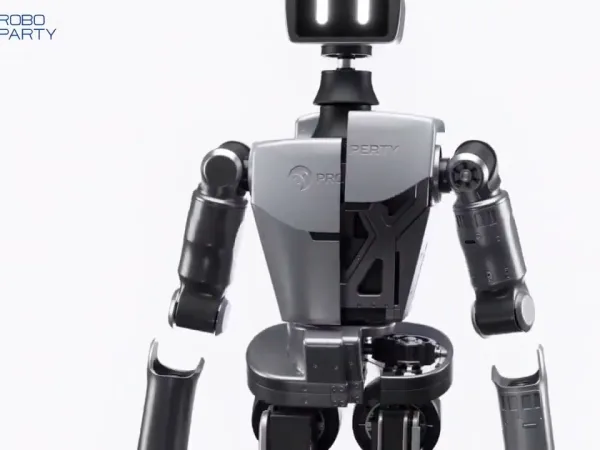
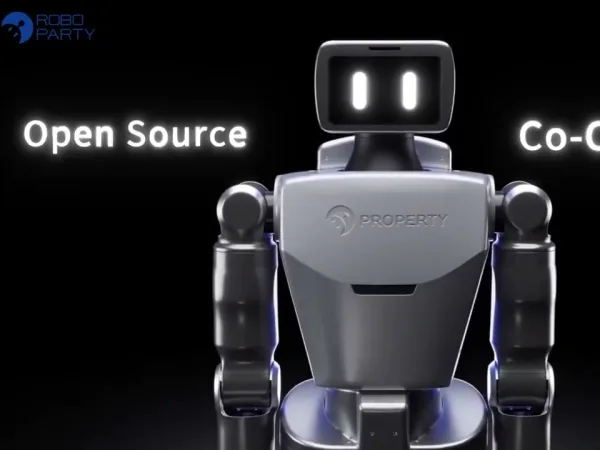
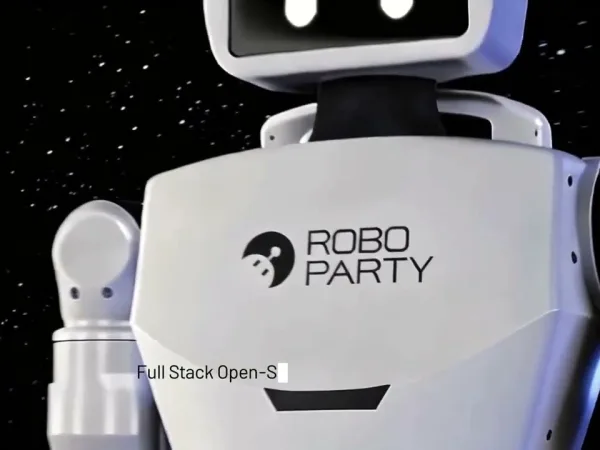
ROBOTO ORIGIN is RoboParty's fully open-source bipedal humanoid prototype, also released as RoboHead (hardware ATOM 01). About 1.25 m tall and 34 kg, it was designed and built in roughly four months in 2025, then open-sourced in January 2026 with structure drawings, BOM, electronics, RL training and deployment code. It can run at about 3 m/s using RoboParty's AMP gait algorithm, and its full bill of materials totals $7,000 (about ¥49,713).
Quick Overview & Key Facts
ROBOTO ORIGIN is a humanoid robot made by RoboParty in China, launched in 2025 and built for learning humanoid robotics, sim-to-real RL research, and DIY builds. Its estimated price is USD 7,000 (About ¥49,713). Featured in “Best Open-Source Humanoid Robots in 2026, Ranked by How Open They Really Are”.
- Dimensions
- Height: 1.25 m
- Weight
- 34 kg (75 lbs)
- Mobility
- Bipedal (legged)
- Handles
- Light research objects
- Battery runtime
- Approx. 1 hour pack and typical biped power draw)
- Charging time
- Approx. 2 hours with a 48 V charger
- Sensors
- Chaohe HI13 USB IMU and joint encoders in the DM motors; optional depth camera for navigation modules
- Operating environment
- Indoor labs and flat outdoor test areas
What Can ROBOTO ORIGIN Do?
Core operational tasks and activities demonstrated or performed by ROBOTO ORIGIN.
ROBOTO ORIGIN Capabilities
Inherent physical, perceptual, and cognitive abilities built into ROBOTO ORIGIN.
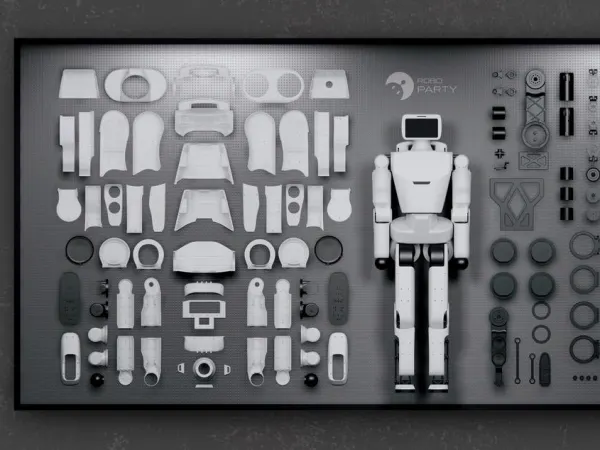
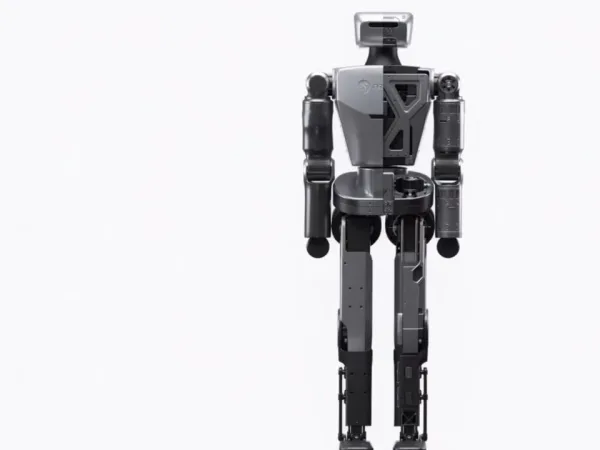
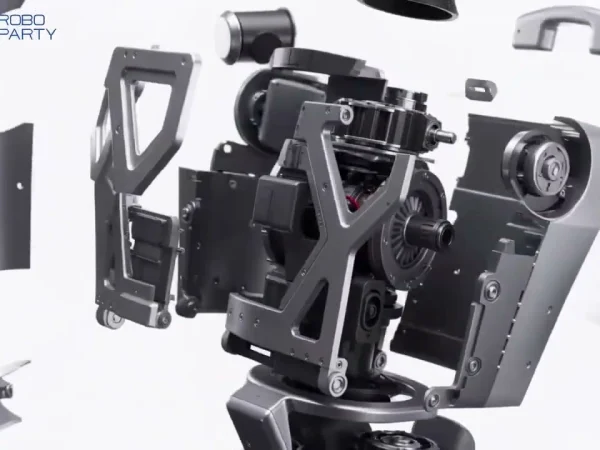
Image Gallery
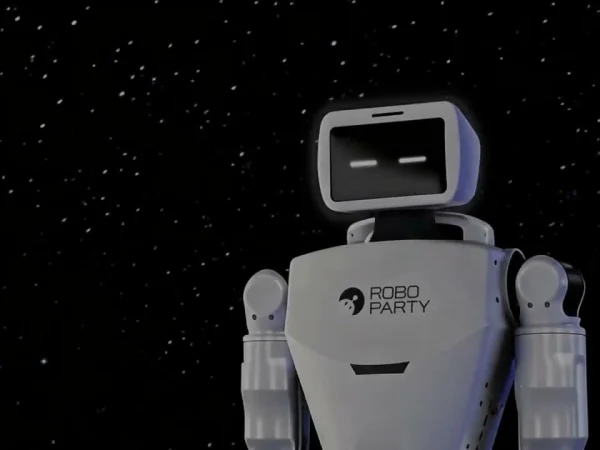
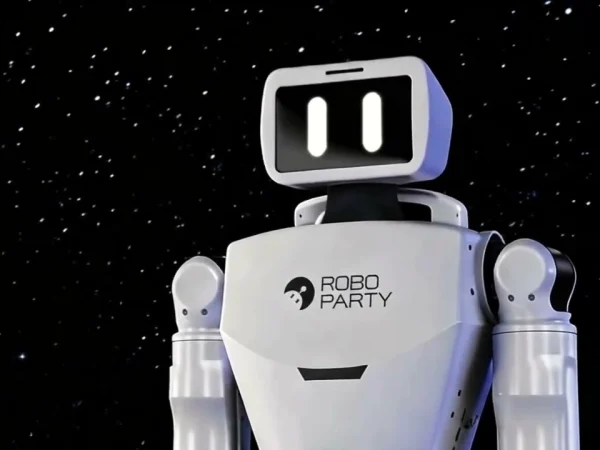
Below images are from RoboParty's official sources
Review Videos
Watch expert reviews and demonstrations of this robot

Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by RoboParty: safety certifications, EMC compliance, IP rating, noise level, expected lifespan, maintenance schedule, update method, color options and 4 more.
Robot Timeline
Key milestones in this robot's development and rollout
ROBOTO ORIGIN prototype built in about four months
Full-stack open-source release on GitHub
Creative workshop and additional motion-control algorithms added to the repository
ROBOTO ORIGIN vs K1 Geek Humanoid, Unitree R1, Adam Lite and K1 Professional Humanoid
ROBOTO ORIGIN overlaps with these alternatives on Developer friendly and Running. ROBOTO ORIGIN leads this group on max speed but trails on runtime and weight.
Industries and capabilities are tags, not scores: a tick means the robot is listed for it. Green marks the best figure in a row (highest max speed and runtime; lowest weight). Ranges are not ranked.
| Spec | ROBOTO ORIGINRoboParty | K1 Geek HumanoidBooster Robotics | Unitree R1Unitree Robotics | Adam LitePNDbotics | K1 Professional HumanoidBooster Robotics |
|---|---|---|---|---|---|
| Capabilities | |||||
| Developer friendly | Yes | Yes | Yes | Yes | No |
| Running | Yes | Yes | Yes | No | Yes |
| Max Speed | 3 m/s | 0.39 m/s | 2.5 m/s | 1.5 m/s | 0.39 m/s |
| Payload | Light research objects | — | 0 g | — | — |
| Runtime | 60 min | 30 min | 60 min | — | 80 min |
| Weight | 34 kg | 19.5 kg | 27 kg | 60 kg | 19.5 kg |
| Released | 2025 | 2025 | 2025 | 2024 | 2025 |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all Humanoid Robots
ROBOTO ORIGIN Also Mentioned in Below Articles
Find out how this model stacks up against the world's best robots

More Robots from RoboParty
Explore other robots from this manufacturer
RP1
Manufactured by RoboParty
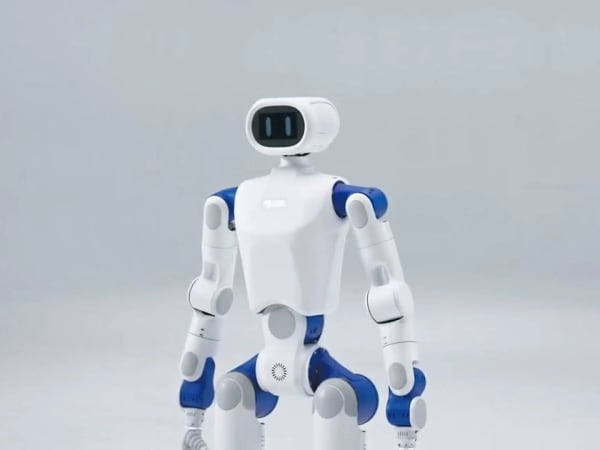
RP1 (also called ROBOTO 01) is a full-size bipedal humanoid robot from RoboParty, the Shanghai team behind the open-source ROBOTO Origin project. It debuted at IROS 2026 in Pittsburgh on September 28, 2026, where visitors were invited to push and kick it in a "Kick Me" demo to show how quickly it recovers its balance and gets back up after a fall. RP1 stands 1.35 m tall and weighs about 39 kg. It has 24 active degrees of freedom, or 30 on the RP1 Pro, and runs on RoboParty's own Romomo joint modules with up to 160 N·m of peak torque. It can run at up to 4 m/s, climb 30° slopes, carry 5 kg per arm and work for about 3 hours on a hot-swappable 10 Ah battery. What sets it apart is that it is open source end to end: RoboParty publishes the structure drawings, bill of materials, PCBs and 3D models, as well as the drivers, gait algorithms, ROS 2 middleware, SDK, simulation and training code. Swappable heads and hands let one robot serve motion-control, perception, data-collection or interaction work. RP1 is built for researchers, universities and embodied-AI teams.
More Humanoid Robots
Discover more robots in the same category
Robots From Other Categories
Discover complementary robots from different categories that work well together
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is ROBOTO ORIGIN, and what problem is it designed to solve?
ROBOTO ORIGIN is RoboParty’s open-source bipedal humanoid robot prototype, intended as a reproducible baseline for research, education, and hands-on development.
Q2. What are the main capabilities and key features of ROBOTO ORIGIN?
According to RoboParty, it provides a full-stack open-source platform covering hardware, control software, and engineering documentation for humanoid locomotion and development.
Q3. Who is ROBOTO ORIGIN built for, and which industries can benefit from it?
RoboParty describes it as aimed at makers, researchers, educators, and developers in robotics, AI, and embodied systems.
Q4. Is ROBOTO ORIGIN a commercial product or still a research prototype?
RoboParty says ROBOTO ORIGIN is a prototype and engineering baseline, not an industrial-grade product for general commercial deployment.
Q5. Is ROBOTO ORIGIN currently available for purchase, and when is it expected to ship?
As of 2026, RoboParty has reported development kit pre-orders and early interest, while shipping depends on distributor fulfillment after order processing.
Q6. How does ROBOTO ORIGIN actually work in real-world environments?
It is designed to run on real hardware with open control and simulation workflows, letting users test motion, tuning, and deployment in practical environments.
Q7. When was ROBOTO ORIGIN announced or officially launched?
RoboParty said it open-sourced ROBOTO ORIGIN in January 2026, after completing development work during 2025.
Q8. How is ROBOTO ORIGIN different from other robots in the same category?
RoboParty positions it as a fully open-source humanoid baseline, with hardware and software documentation released for replication and further development.
Q9. Does ROBOTO ORIGIN require additional development or customization after purchase?
Yes, RoboParty presents it as a development platform that typically requires integration, tuning, and application-specific customization.
Q10. What is the future roadmap or planned upgrades for ROBOTO ORIGIN?
The company has announced plans to expand the platform through broader developer use, additional tooling, and continued open-source ecosystem development.
Rating and Reviews
Share your experience and help others decide!
Loading...
User Reviews
No user reviews. Be the first one to review!
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.