
HRP-3
AI ChatLast updated:
The HRP-3 humanoid robot, developed by Kawada Industries in collaboration with AIST and Kawasaki Heavy Industries, represents a significant advancement in bipedal robotics for harsh environments. Standing at 160 cm tall and weighing 68 kg, it features 36-42 degrees of freedom, enabling complex manipulations and stable locomotion on slippery or uneven surfaces. Designed for disaster relief, construction, and industrial tasks, HRP-3 boasts dustproof and water-resistant construction, allowing operation under heavy rain or dust. Enhanced leg-arm coordination supports carrying heavy loads, while autonomous/remote hybrid control improves task efficiency. Equipped with stereo cameras, gyroscopes, accelerometers, and force sensors, it navigates challenging terrains, recovers from falls, and performs collaborative work with humans. Its robust hardware and advanced software make it a pioneer in practical humanoid applications beyond laboratories.
No public way to buy it as of Nov 2026.
Quick Overview & Key Facts
HRP-3 is a humanoid robot made by Kawada Robotics in Japan, launched in 2006 and built for hazardous environment tasks, human-robot cooperation, and heavy lifting in construction. Its estimated price is USD 500,000-1,000,000.
- Dimensions
- 160 x 60 x 29 (cm)
- Weight
- 68 kg
- Mobility
- Legged (bipedal walking)
- Top speed
- 2.5 km/h (0.7 m/s)
- Handles
- tools, packages, precision instruments
- Battery runtime
- 2 hours
- Charging time
- 4 hours
- Sensors
- stereo cameras, three-axis gyro, three-axis accelerometer, motor encoders, six-axis force sensors, scanning range finder
- Operating environment
- both
What Can HRP-3 Do?
Core operational tasks and activities demonstrated or performed by HRP-3.
Real-World Applications of HRP-3
Industries, working environments, and deployment suitability for HRP-3.
HRP-3 Capabilities
Inherent physical, perceptual, and cognitive abilities built into HRP-3.
Image Gallery
Below images are from Kawada Robotics's official sources
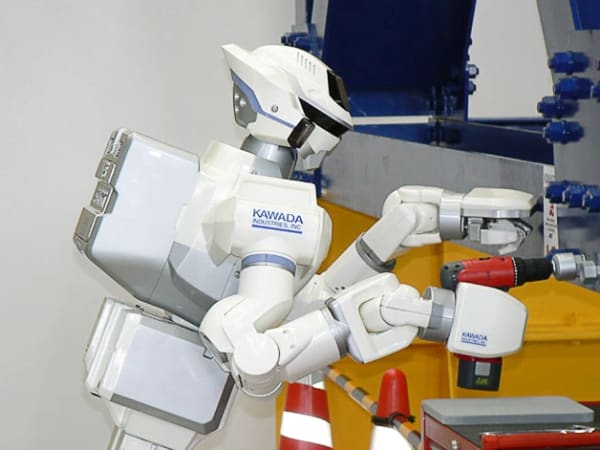
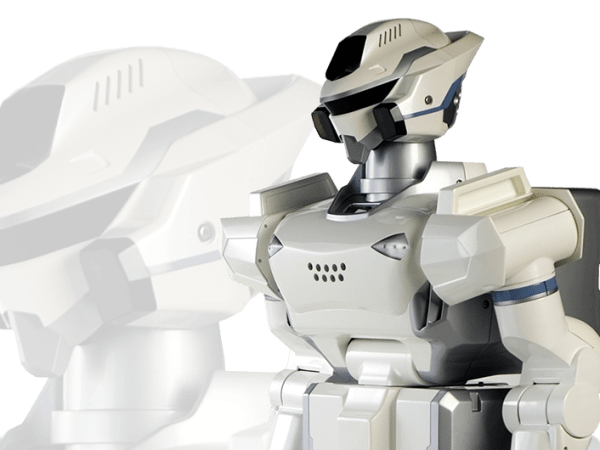
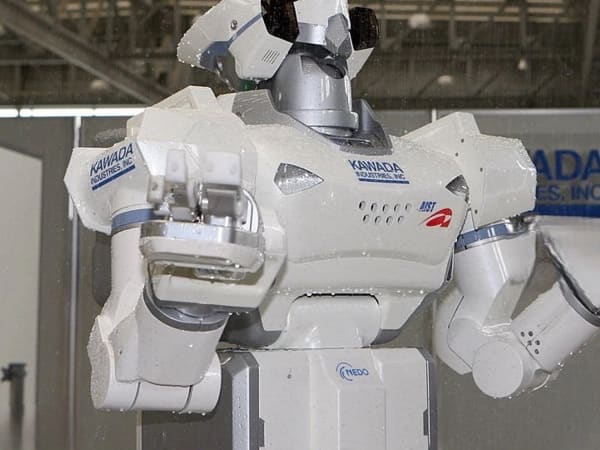
Review Videos
Watch expert reviews and demonstrations of this robot


Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by Kawada Robotics: warranty terms, safety certifications, EMC compliance, IP rating, noise level, expected lifespan, maintenance schedule, firmware version and 7 more.
Robot Timeline
Key milestones in this robot's development and rollout
HRP-3 Promet Mk-II is announced as the final product of the NEDO project on humanoids working in real environments, with dustproof and drip-proof features and walking on slippery surfaces.
Source: Kawada Robotics ↗
Kawada and AIST announce the HRP-4, the "slim athlete" successor to the HRP-3.
Source: Kawada Robotics ↗
HRP-3 vs Talos, Walker X, Kengo and Dyno
HRP-3 overlaps with these alternatives on Construction and Hazardous environments. HRP-3 leads this group on runtime but trails on max speed and weight.
Industries and capabilities are tags, not scores: a tick means the robot is listed for it. Green marks the best figure in a row (highest max speed and runtime; lowest weight). Ranges are not ranked.
| Spec | HRP-3Kawada Robotics | TalosPAL Robotics | Walker XUBTECH Robotics | KengoGalaxea Dynamics | DynoVinDynamics |
|---|---|---|---|---|---|
| Industries | |||||
| Construction | Yes | Yes | No | Yes | No |
| Hazardous environments | Yes | Yes | No | No | No |
| Industrial automation | Yes | Yes | No | Yes | Yes |
| Manufacturing | Yes | Yes | No | Yes | Yes |
| Capabilities | |||||
| Force control | Yes | Yes | Yes | Yes | No |
| Stair climbing | Yes | Yes | Yes | Yes | No |
| Terrain traversal | Yes | Yes | Yes | Yes | No |
| Tool use | Yes | Yes | Yes | Yes | No |
| Max Speed | 0.69 m/s | 0.83 m/s | 0.83 m/s | 1.39 m/s | — |
| Runtime | 120 min | 90 min | 120 min | 120 min | — |
| Weight | 68 kg | 95 kg | 63 kg | 40 kg | 75 kg |
| Released | 2006 | 2017 | 2021 | 2026 | 2026 |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all Humanoid Robots
More Robots from Kawada Robotics
Explore other robots from this manufacturer
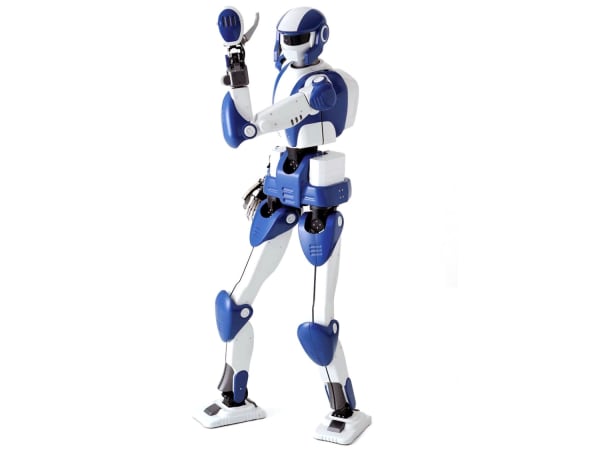
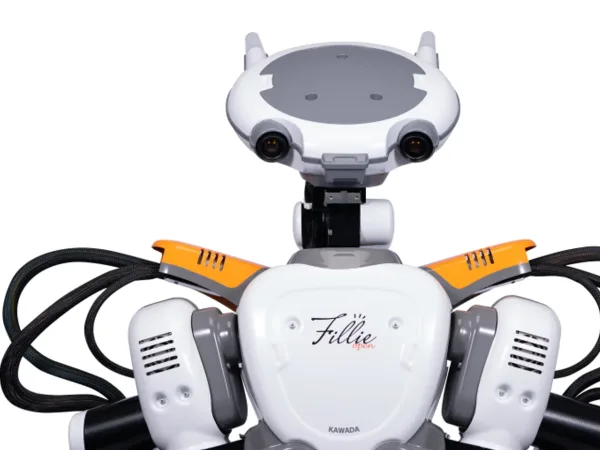
More Humanoid Robots
Discover more robots in the same category
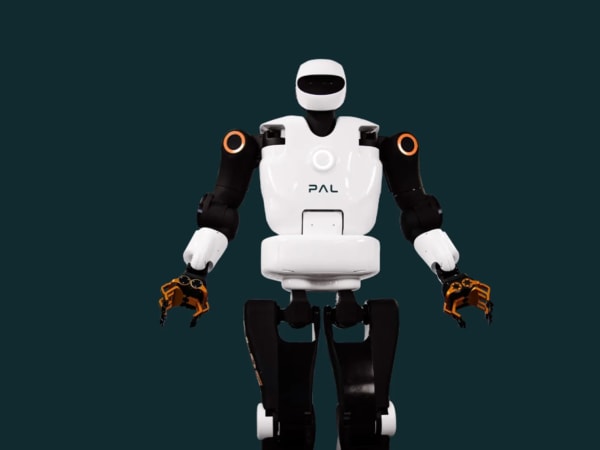
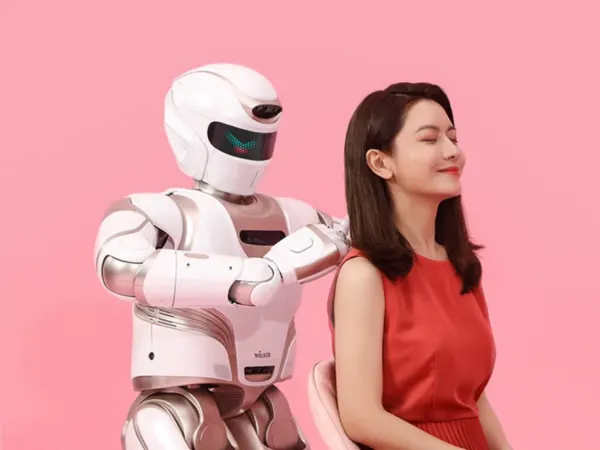
Robots From Other Categories
Discover complementary robots from different categories that work well together
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is HRP-3, and what problem is it designed to solve?
HRP-3 Promet Mk-II is a humanoid robot developed jointly by Kawada Industries, Kawasaki Heavy Industries, and AIST. It is designed to operate in adverse environments, addressing challenges in real-world tasks under a NEDO project launched in 2002.
Q2. What are the main capabilities and key features of HRP-3?
HRP-3 features mechanical and structural components to prevent dust or spray penetration, with redesigned wrists and hands for improved manipulation. It builds on HRP-2's bipedal locomotion for rough terrain and self-protection from tipping over.
Q3. Who is HRP-3 built for, and which industries can benefit from it?
HRP-3 was developed as part of Japan's Humanoid Robotics Project for research and practical applications. It targets industries needing robots in harsh conditions, such as construction and manufacturing, according to project collaborators.
Q4. Is HRP-3 a commercial product or still a research prototype?
HRP-3 is a research prototype from the Humanoid Robotics Project, led by Kawada Industries and AIST. It served as a platform for advancing humanoid technology rather than direct commercialization.
Q5. Is HRP-3 currently available for purchase, and when is it expected to ship?
As of 2026, HRP-3 is not available for purchase, having been a project-specific prototype. No shipping timelines were announced, as it preceded later commercial efforts like NEXTAGE.
Q6. How does HRP-3 actually work in real-world environments?
HRP-3 integrates hardware from Kawada, software from AIST, and remote control from Kawasaki for operation in adverse settings. It handles rough terrain and manipulation tasks, with dust-resistant design for practical testing.
Q7. When was HRP-3 announced or officially launched?
HRP-3 Promet Mk-II was announced on June 21, 2007, by Kawasaki Heavy Industries, Kawada Industries, and AIST. It resulted from a five-year NEDO project started in 2002.
Q8. How is HRP-3 different from other robots in the same category?
HRP-3 emphasizes dust and spray resistance plus enhanced hand manipulation, differing from predecessors like HRP-2. It focuses on real-world adverse environments, unlike platforms such as Fujitsu's HOAP series.
Q9. Does HRP-3 require additional development or customization after purchase?
As a research prototype, HRP-3 required software and control integration by project partners. No standard purchase model existed, so customization was inherent to its development process.
Q10. What is the future roadmap or planned upgrades for HRP-3?
Kawada Technologies has refreshed HRP-2 systems and aims to develop advanced humanoids for construction sites. The HRP series informs ongoing efforts toward robots resilient to falls and unstable terrain.
Rating and Reviews
Share your experience and help others decide!
Loading...
User Reviews
No user reviews. Be the first one to review!
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.