
HRP-4
AI ChatLast updated:
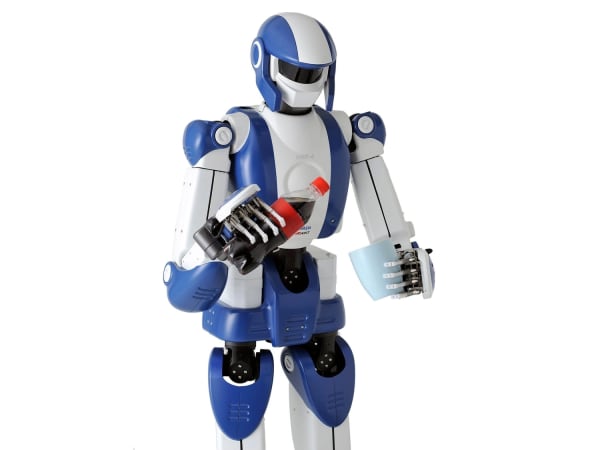
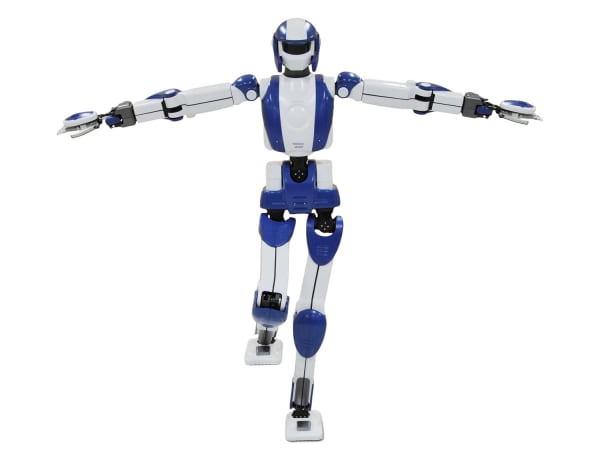
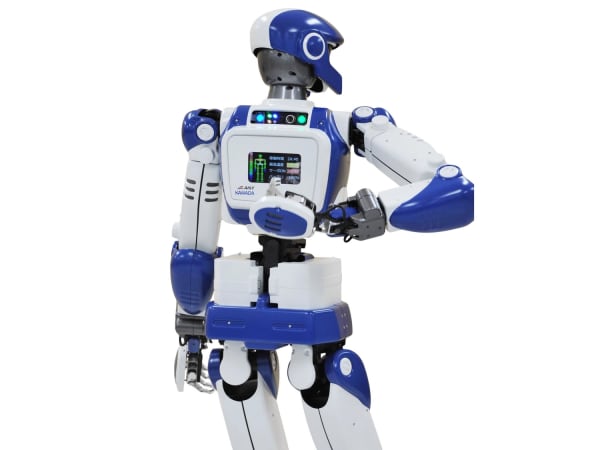
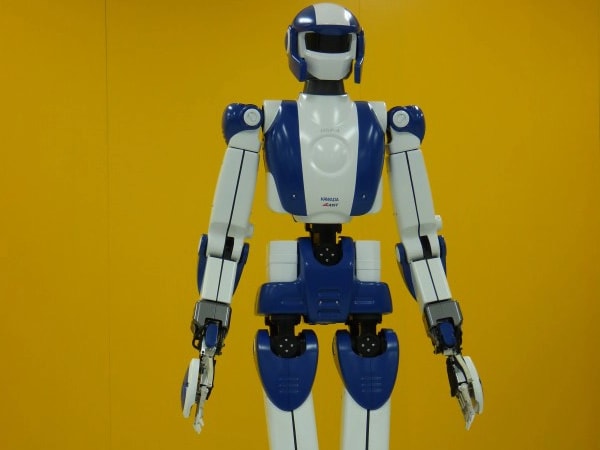
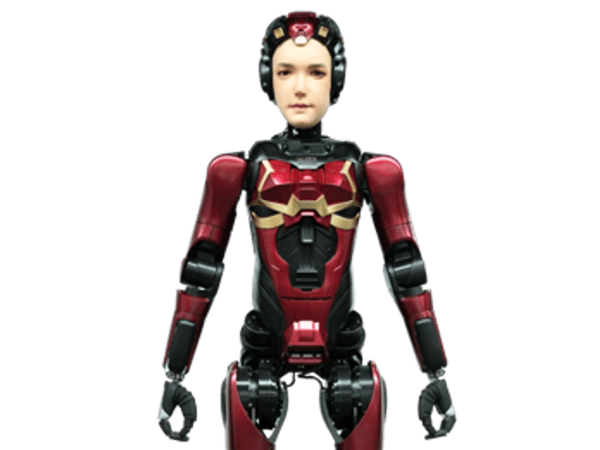
The HRP-4 is a lightweight, slim humanoid robotics platform developed for advanced research in human-robot collaboration and bipedal locomotion. Standing at 151 cm tall and weighing just 39 kg, it features 34 degrees of freedom, including 7 DOF per arm for precise object manipulation and 6 DOF per leg for stable walking. Equipped with low-power motors under 80W for enhanced safety around humans, it performs natural movements like waist twisting, one-footed balance, and dexterous five-fingered hand grasping. Cameras and microphones enable face recognition, object tracking, and voice command response. Designed as a successor to HRP-2 and HRP-3, HRP-4 supports indoor navigation in human environments, with flexible joints for athletic poses and tasks. Its compact, human-proportioned body facilitates safer interaction, object handling up to 0.5 kg per arm, and motion control software from AIST, accelerating humanoid R&D for practical applications like assistive work.
No public way to buy it as of Nov 2026.
Quick Overview & Key Facts
HRP-4 is a humanoid robot made by Kawada Robotics in Japan, launched in 2010 and built for humanoid research, object manipulation, and assistive tasks. Its estimated price is USD 300,000 - 305,000. Featured in “Japanese Humanoid Robots in 2026: Every Major Model Compared”.
- Dimensions
- 151 x 44 x 26 (cm)
- Weight
- 39 kg
- Mobility
- Legged (bipedal walking)
- Top speed
- 2.5 km/h (0.7 m/s)
- Handles
- Tools, packages, precision instruments, people interaction
- Battery runtime
- 2 hours
- Charging time
- 3 Hours
- Sensors
- RGB cameras (head and arms), stereo cameras, microphones, IMU, gyroscope, force sensors
- Operating environment
- Indoor
What Can HRP-4 Do?
Core operational tasks and activities demonstrated or performed by HRP-4.
Real-World Applications of HRP-4
Industries, working environments, and deployment suitability for HRP-4.
HRP-4 Capabilities
Inherent physical, perceptual, and cognitive abilities built into HRP-4.
Image Gallery
Below images are from Kawada Robotics's official sources
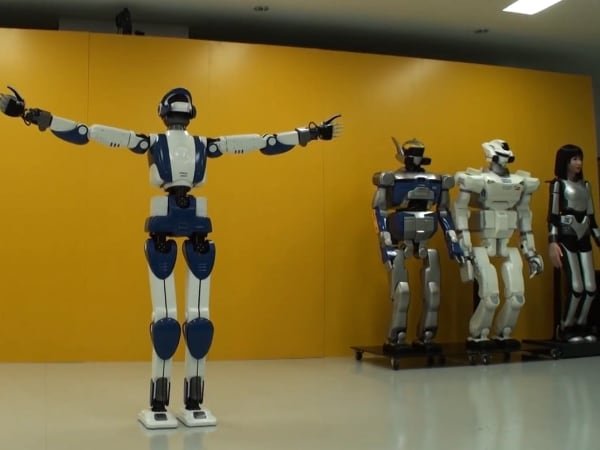
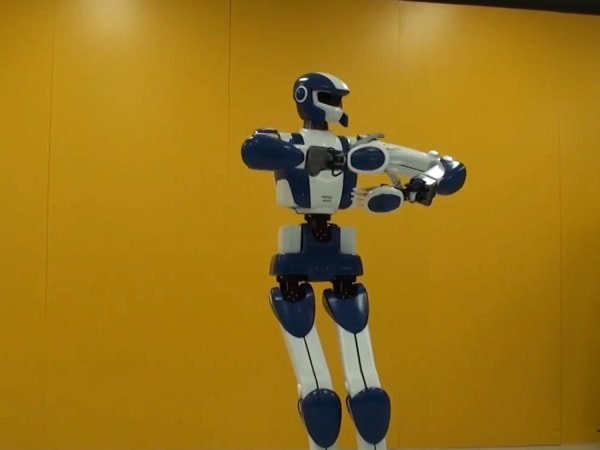
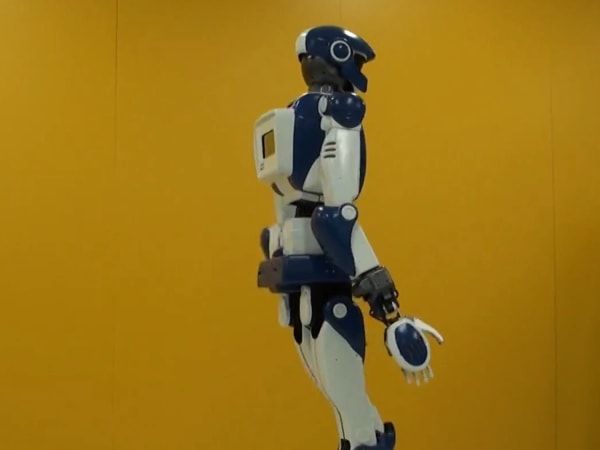
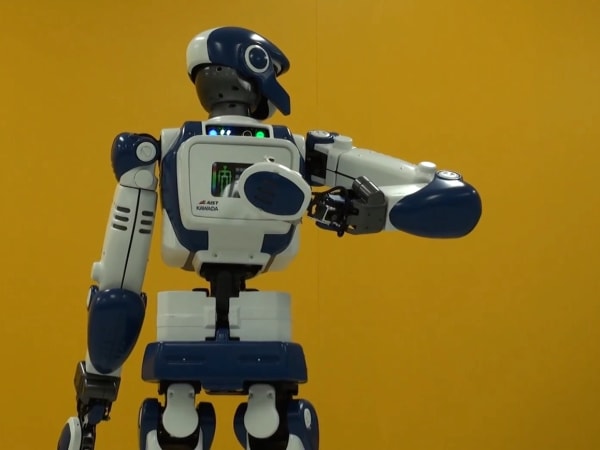
Review Videos
Watch expert reviews and demonstrations of this robot

Robot Specifications
Values without a Confirmed badge are compiled from public sources and may not be manufacturer-verified.
Not yet published by Kawada Robotics: warranty terms, safety certifications, EMC compliance, IP rating, noise level, expected lifespan, maintenance schedule, firmware version and 6 more.
Robot Timeline
Key milestones in this robot's development and rollout
HRP-3 Promet Mk-II is announced as the final product of the NEDO humanoid project, the platform that precedes the HRP-4.
Source: Kawada Robotics ↗
Kawada and AIST announce the HRP-4, a research humanoid built on a "slim athlete" concept, about 150 cm tall and 39 kg.
Source: Kawada Robotics ↗
HRP-4 vs ASIMO 2.0, HRP-3, VR-H1 and Xia Lan S02
HRP-4 overlaps with these alternatives on Education and training and Industrial automation. HRP-4 leads this group on runtime and weight but trails on max speed.
Industries and capabilities are tags, not scores: a tick means the robot is listed for it. Green marks the best figure in a row (highest max speed and runtime; lowest weight). Ranges are not ranked.
| Spec | HRP-4Kawada Robotics | ASIMO 2.0Honda | HRP-3Kawada Robotics | VR-H1VinRobotics | Xia Lan S02Digit Robotics |
|---|---|---|---|---|---|
| Industries | |||||
| Education and training | Yes | Yes | No | No | No |
| Industrial automation | Yes | No | Yes | Yes | Yes |
| Manufacturing | Yes | No | Yes | Yes | Yes |
| Research and development | Yes | Yes | Yes | Yes | Yes |
| Capabilities | |||||
| Force control | Yes | No | Yes | No | No |
| Human-robot interaction | Yes | Yes | No | No | No |
| Stair climbing | Yes | Yes | Yes | No | No |
| Tool use | Yes | No | Yes | No | No |
| Max Speed | 0.69 m/s | 2.5 m/s | 0.69 m/s | 1.5 m/s | 1.5 m/s |
| Runtime | 120 min | 60 min | 120 min | 2–4 h | 120 min |
| Weight | 39 kg | 48 kg | 68 kg | 75 kg | 69 kg |
| Released | 2010 | 2000; 2005; 2011 | 2006 | 2025 | 2025 |
Notes such as conditions or alternate figures are left out and values are shown in common units; open each page for the full specs. Browse all Humanoid Robots
HRP-4 Also Mentioned in Below Articles
Find out how this model stacks up against the world's best robots

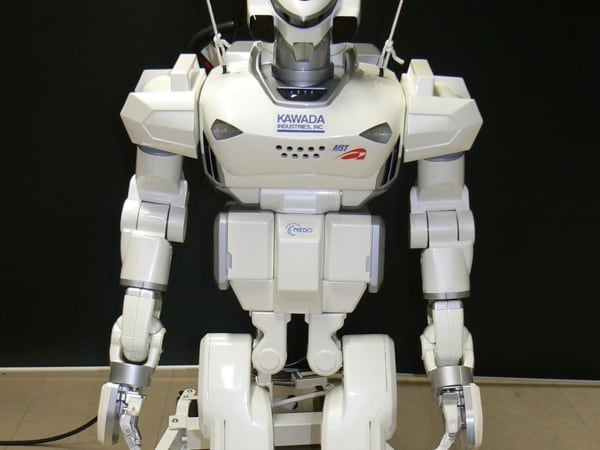
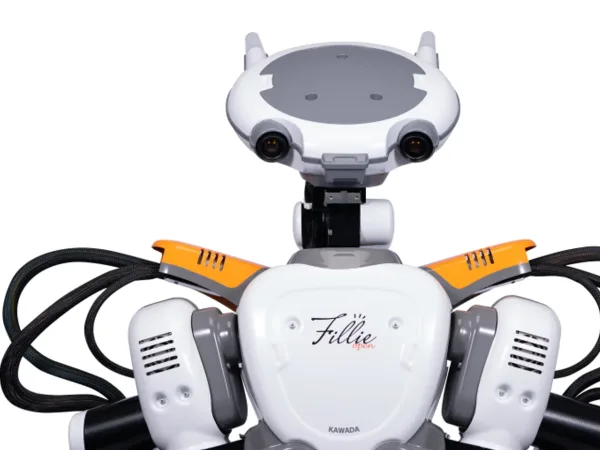
More Robots from Kawada Robotics
Explore other robots from this manufacturer
More Humanoid Robots
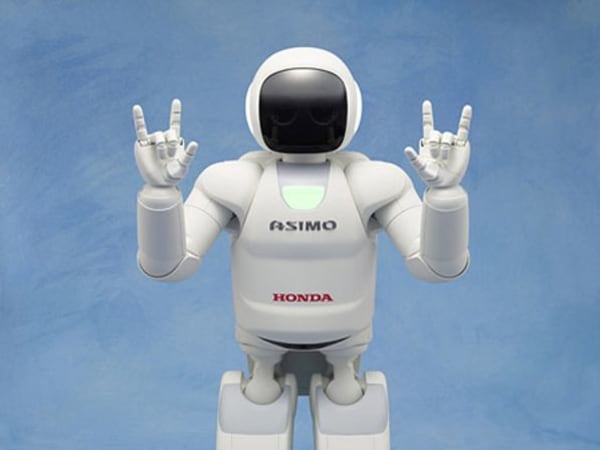
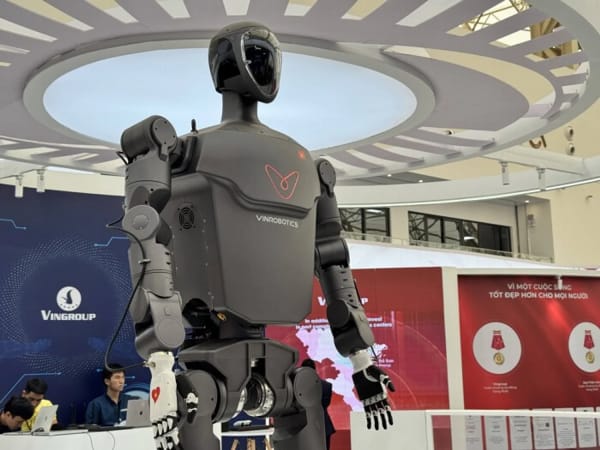
Discover more robots in the same category
Robots From Other Categories
Discover complementary robots from different categories that work well together
Frequently Asked Questions
Get answers to common questions about this robot
Q1. What is HRP-4, and what problem is it designed to solve?
HRP-4 is a humanoid robot developed by Kawada Industries in collaboration with AIST as a research and development platform for working humanoid robots. It addresses challenges in creating robots that safely coexist and interact with humans in shared environments.
Q2. What are the main capabilities and key features of HRP-4?
HRP-4 features a lightweight, compact design with enhanced arm mobility for object handling and low-power motors for safety during human collaboration. According to developers, it supports natural movements and interactive technologies research.
Q3. Who is HRP-4 built for, and which industries can benefit from it?
HRP-4 targets universities and research institutions focused on humanoid robotics. It benefits fields like robotics R&D, human-robot interaction, and technologies for future industrial applications.
Q4. Is HRP-4 a commercial product or still a research prototype?
HRP-4 serves as a research and development platform rather than a consumer product. Kawada Industries manufactured it for supply to academic and research entities starting in 2011.
Q5. Is HRP-4 currently available for purchase, and when is it expected to ship?
As of 2026, HRP-4 is not listed for general purchase, having been supplied to research institutions since January 2011. Availability follows orders through Kawada Industries for qualified buyers.
Q6. How does HRP-4 actually work in real-world environments?
HRP-4 operates via hardware from Kawada Industries and motion control software from AIST, enabling bipedal walking and object manipulation. Its design emphasizes safe human coexistence through lighter build and low-power actuators.
Q7. When was HRP-4 announced or officially launched?
HRP-4 was unveiled in September 2010 through a joint project between Kawada Industries and AIST. Production and orders began in January 2011 for research users.
Q8. How is HRP-4 different from other robots in the same category?
Compared to prior HRP series models, HRP-4 is lighter, slimmer, and more compact, with increased arm degrees of freedom and low-power motors. These changes improve safety and suitability for human interaction research.
Q9. Does HRP-4 require additional development or customization after purchase?
HRP-4 is provided as a platform intended for research customization. Users typically integrate additional software and adaptations for specific humanoid robotics experiments.
Q10. What is the future roadmap or planned upgrades for HRP-4?
Kawada Robotics has continued humanoid platform development beyond HRP-4, including models like NEXTAGE OPEN. The company aims to advance research toward practical working robots coexisting with humans.
Rating and Reviews
Share your experience and help others decide!
Loading...
User Reviews
No user reviews. Be the first one to review!
User Comments (No Login needed)
Share your thoughts, experiences, or questions about this robot.
Comments appear after moderator review.